

Probreg is a library that implements point cloud registration algorithms with probablistic model.
The point set registration algorithms using stochastic model are more robust than ICP(Iterative Closest Point). This package implements several algorithms using stochastic models and provides a simple interface with Open3D.
- Open3D interface
- Rigid and non-rigid transformation
- Maximum likelihood when the target or source point cloud is observation data
- Coherent Point Drift (2010)
- Extended Coherent Point Drift (2016) (add correspondence priors to CPD)
- Color Coherent Point Drift (2018)
- FilterReg (CVPR2019)
- Variational Bayesian inference
- Distance minimization of two probabilistic distributions
- Hierarchical Stocastic model
| type | CPD | SVR, GMMReg | GMMTree | FilterReg | BCPD (experimental) |
|---|---|---|---|---|---|
| Rigid | Scale + 6D pose | 6D pose | 6D pose | 6D pose (Point-to-point, Point-to-plane, FPFH-based) |
- |
| NonRigid | Affine, MCT | TPS | - | Deformable Kinematic (experimental) |
Combined model (Rigid + Scale + NonRigid-term) |
You need to install cupy.
pip install cupy
You can install probreg using pip.
pip install probreg
Or install probreg from source.
git clone https://github.com/neka-nat/probreg.git --recursive
cd probreg
pip install -e .
This is a sample code that reads a PCD file and calls CPD registration. You can easily execute registrations from Open3D point cloud object and draw the results.
import copy
import numpy as np
import open3d as o3
from probreg import cpd

# load source and target point cloud
source = o3.io.read_point_cloud('bunny.pcd')
source.remove_non_finite_points()
target = copy.deepcopy(source)
# transform target point cloud
th = np.deg2rad(30.0)
target.transform(np.array([[np.cos(th), -np.sin(th), 0.0, 0.0],
                           [np.sin(th), np.cos(th), 0.0, 0.0],
                           [0.0, 0.0, 1.0, 0.0],
                           [0.0, 0.0, 0.0, 1.0]]))
source = source.voxel_down_sample(voxel_size=0.005)
target = target.voxel_down_sample(voxel_size=0.005)

# compute cpd registration
tf_param, _, _ = cpd.registration_cpd(source, target)
result = copy.deepcopy(source)
result.points = tf_param.transform(result.points)

# draw result
source.paint_uniform_color([1, 0, 0])
target.paint_uniform_color([0, 1, 0])
result.paint_uniform_color([0, 0, 1])
o3.visualization.draw_geometries([source, target, result])| CPD | SVR | GMMTree | FilterReg |
|---|---|---|---|
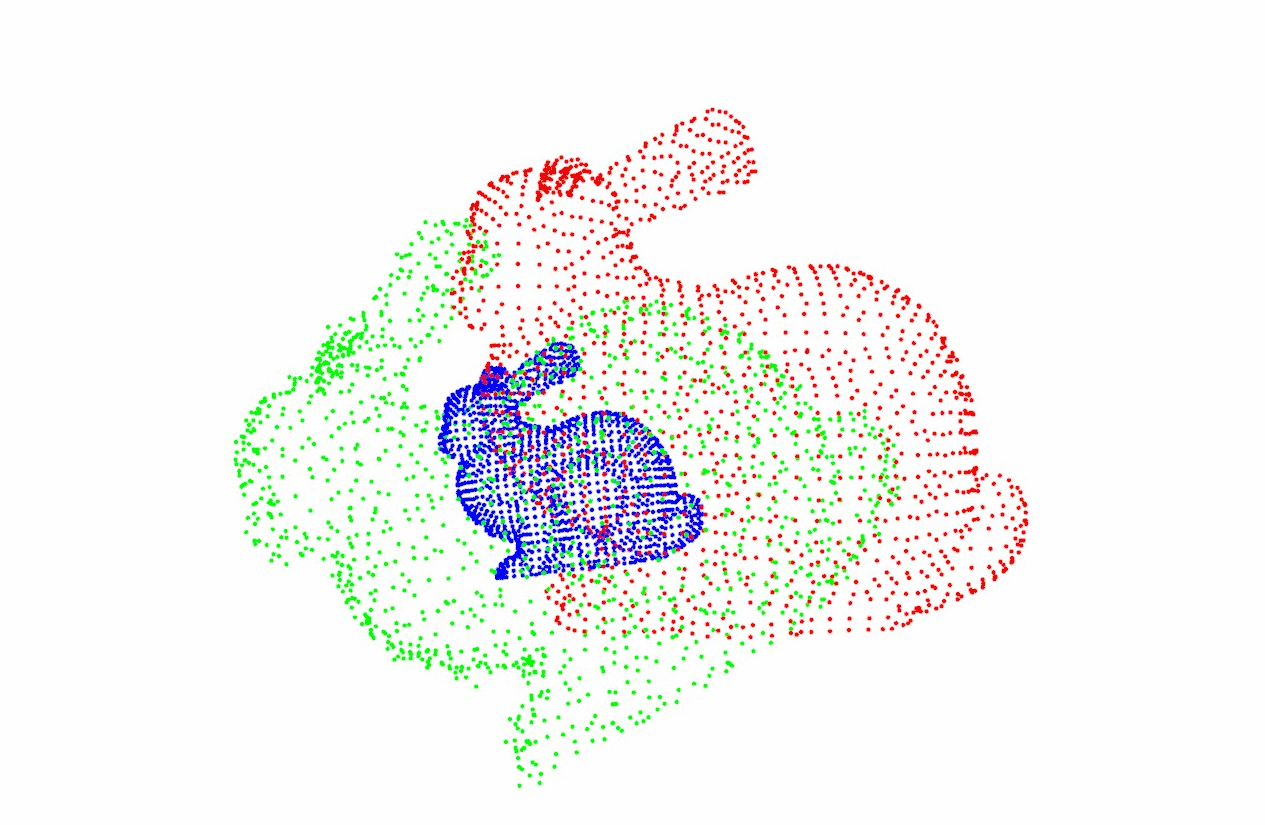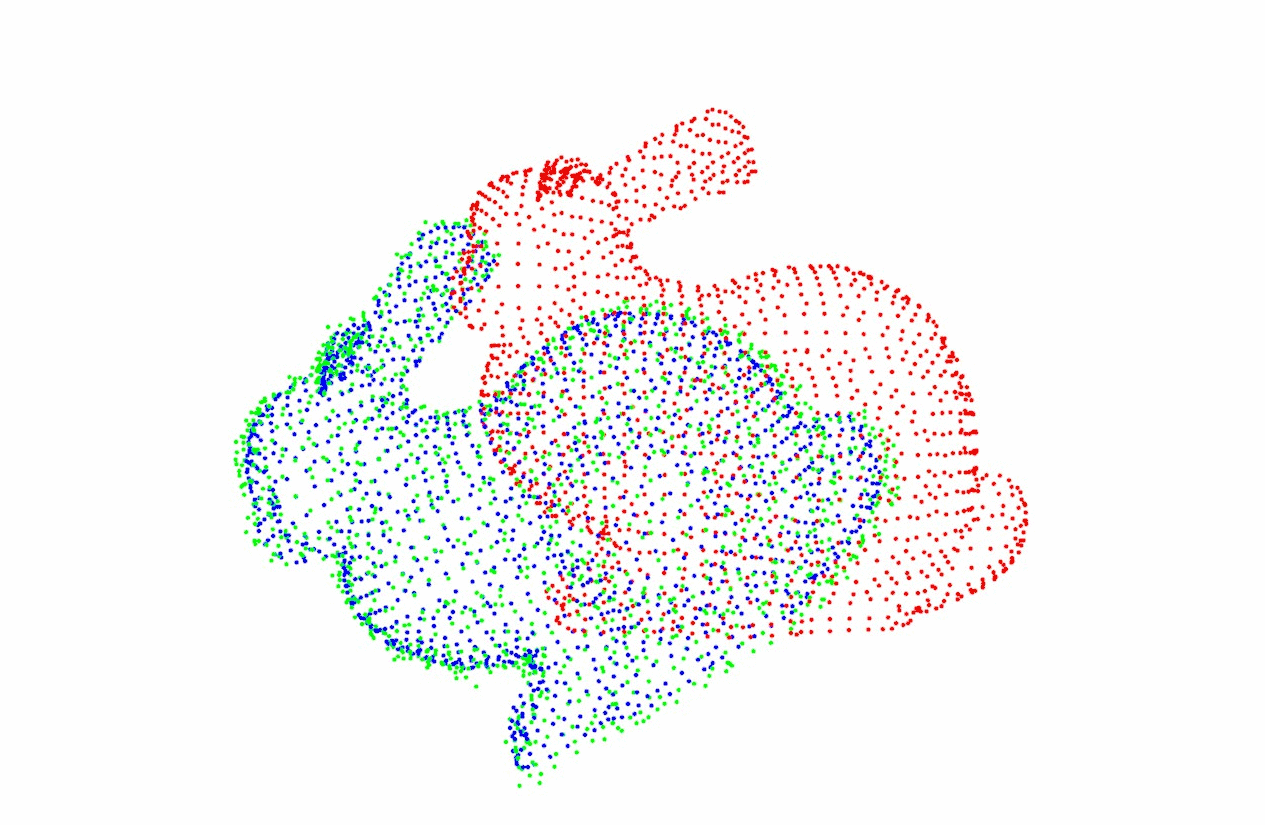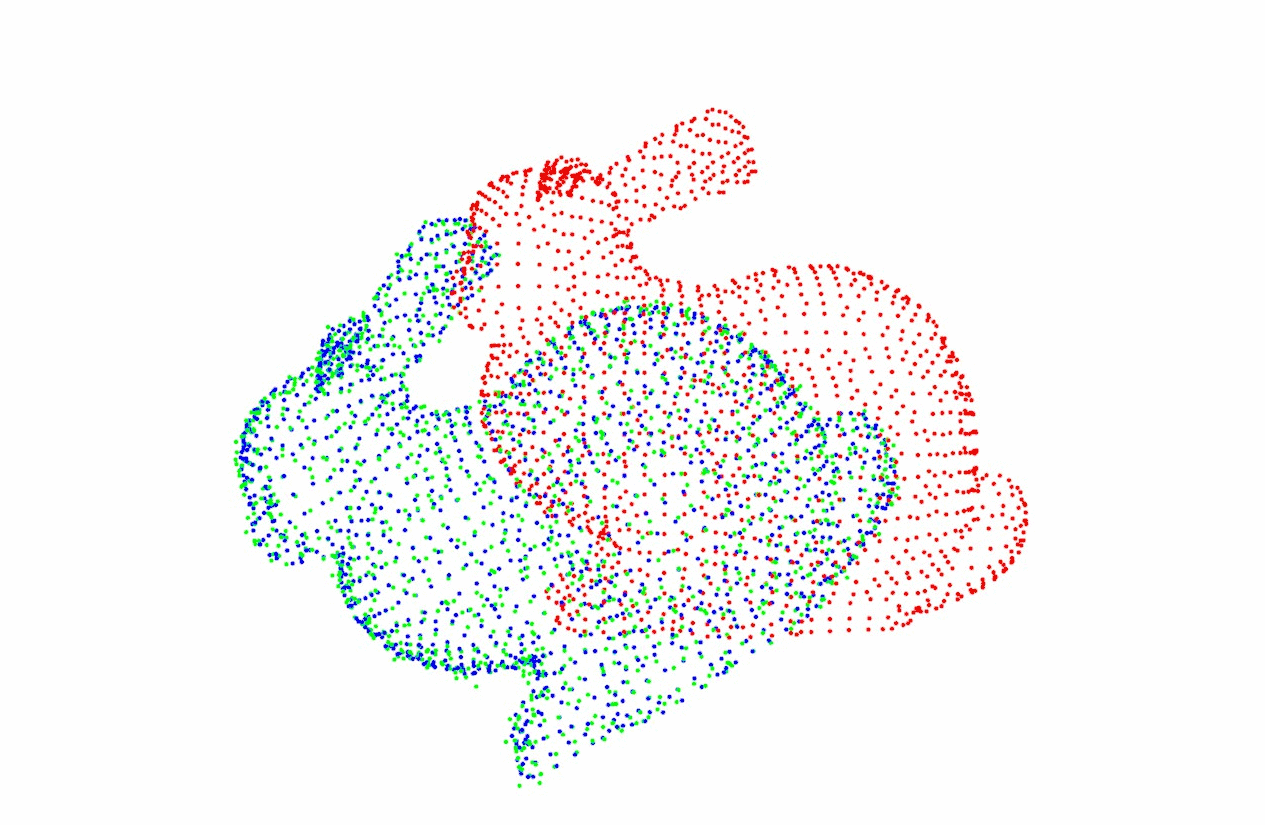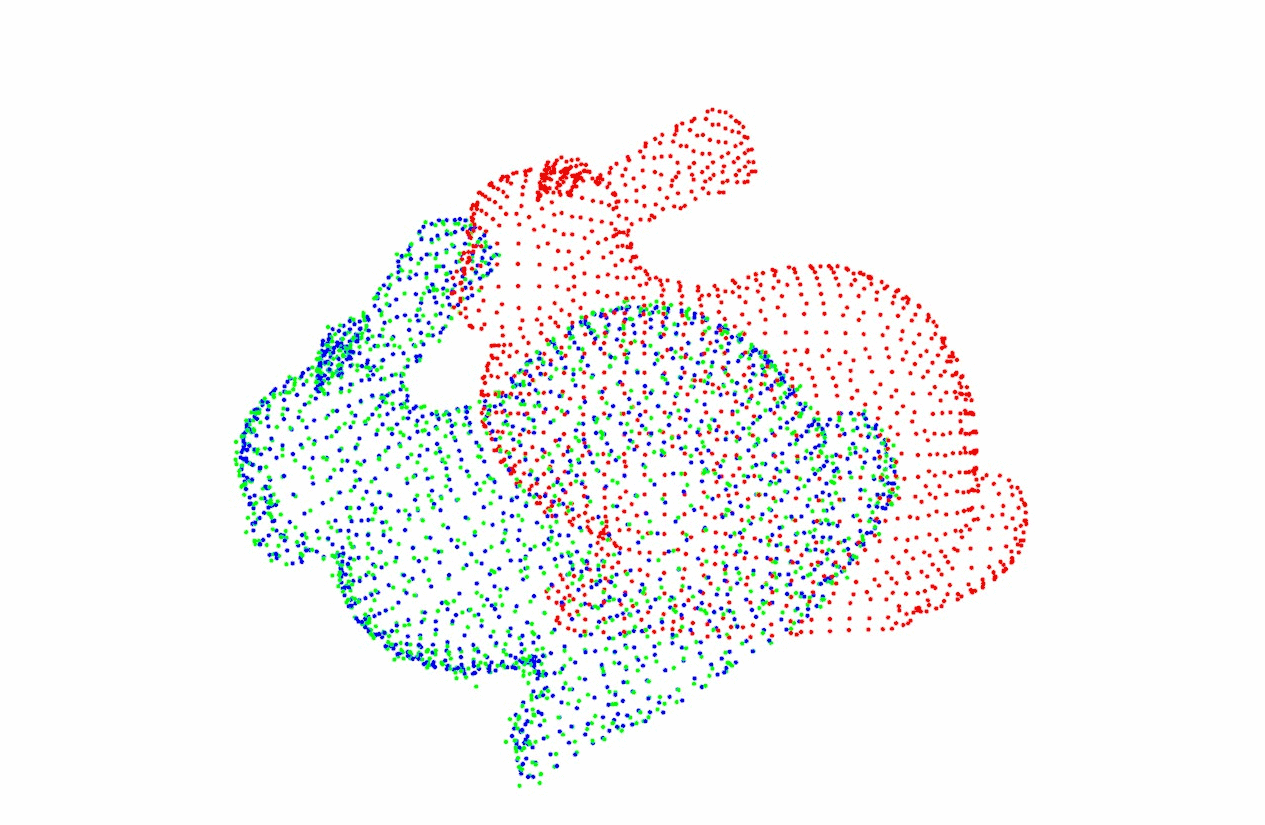 |
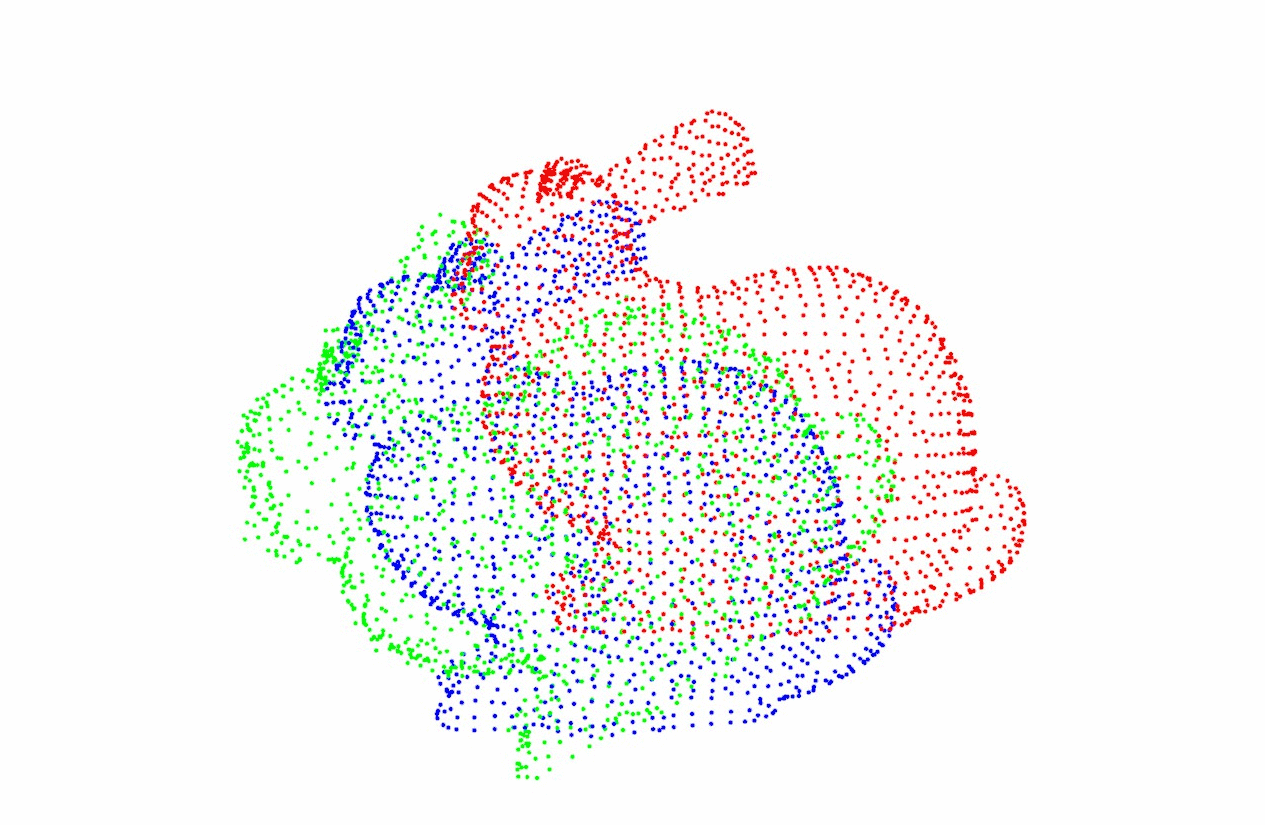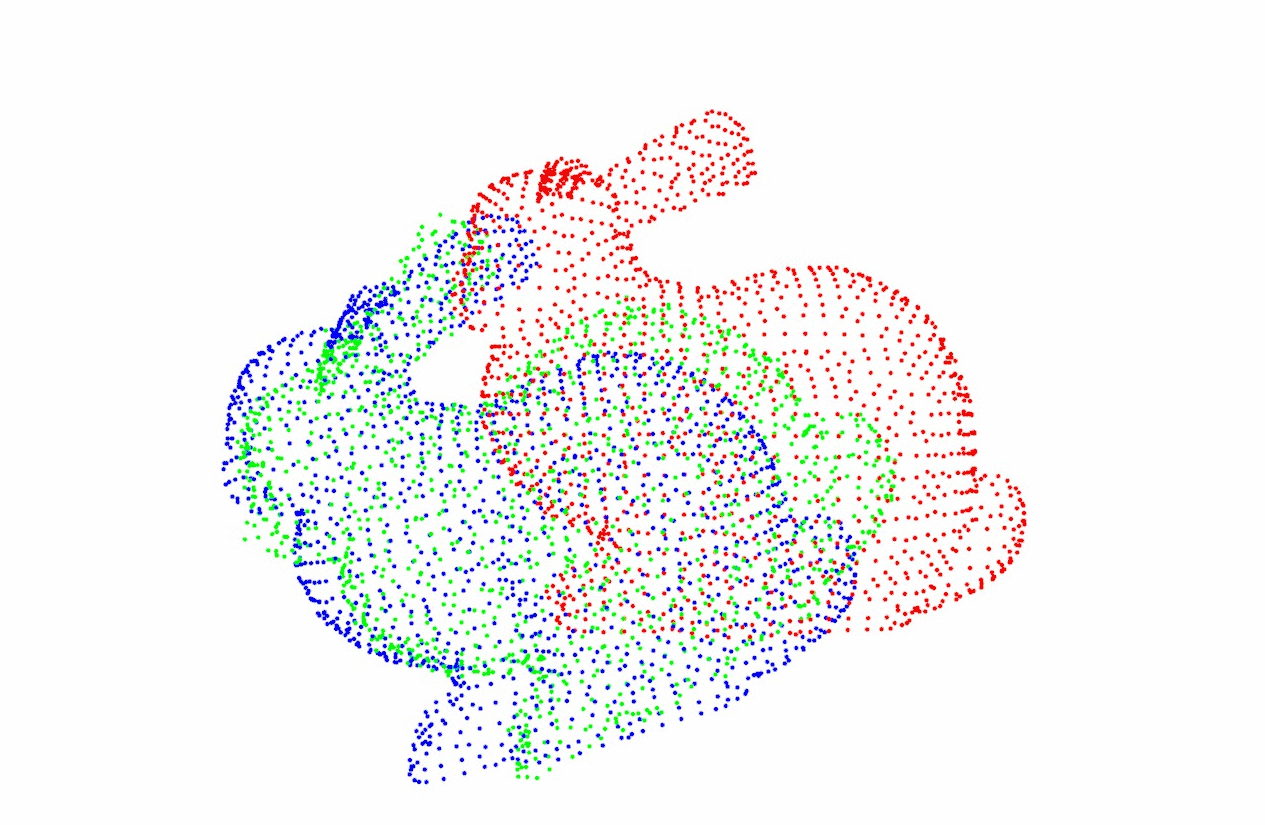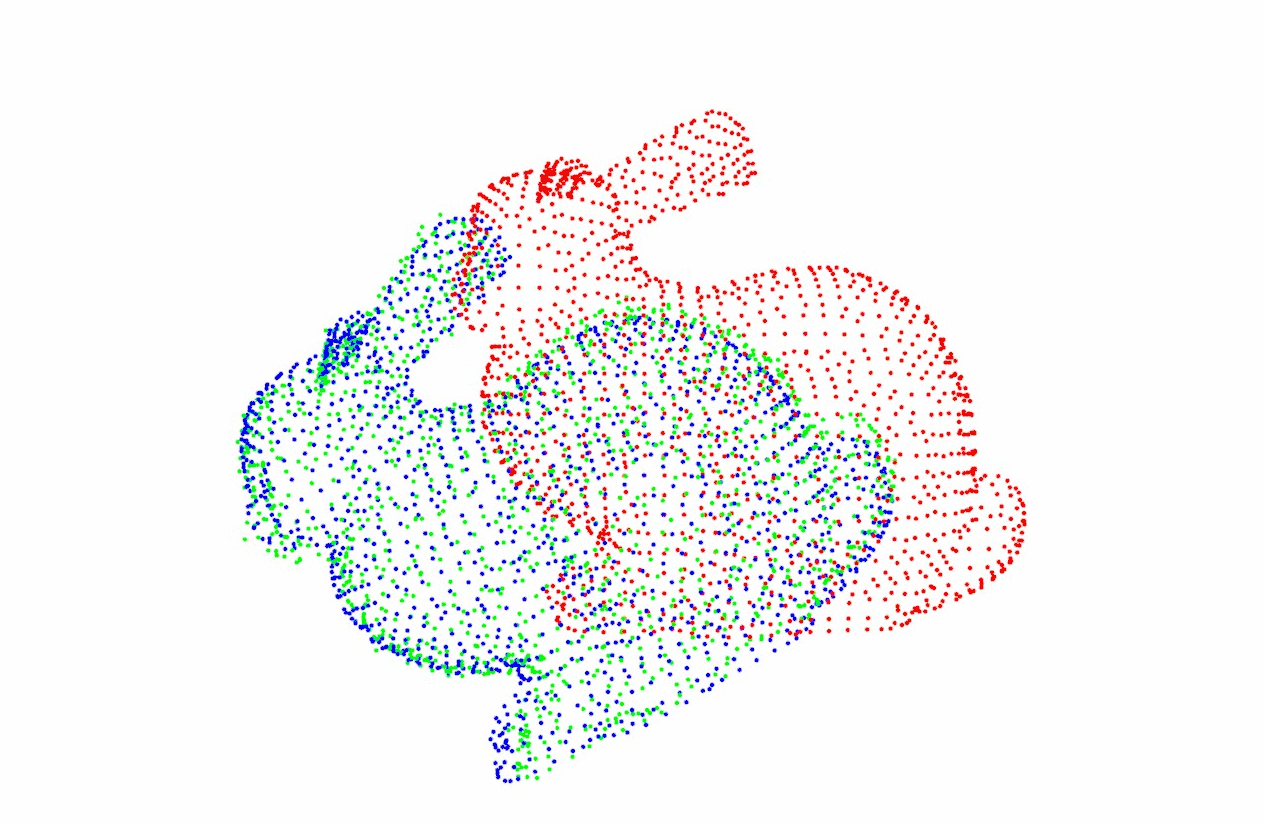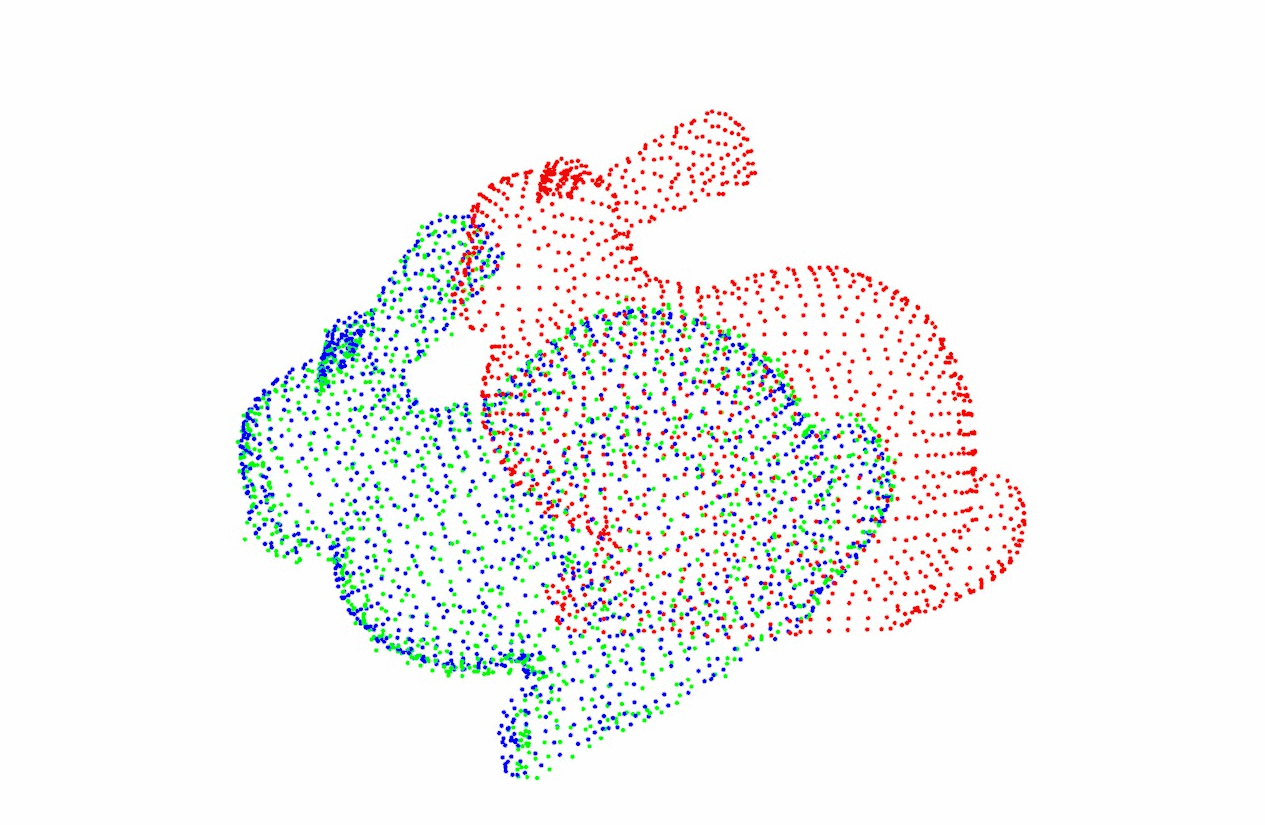 |
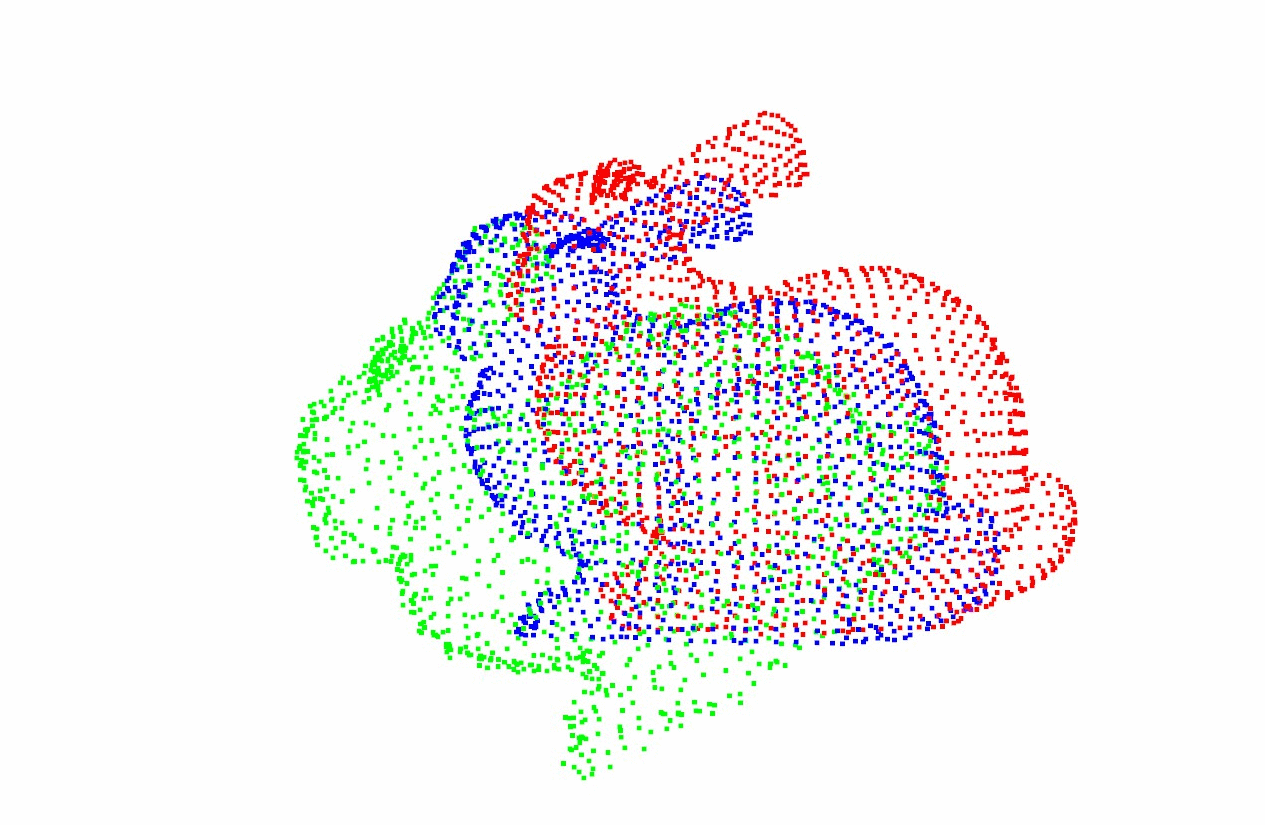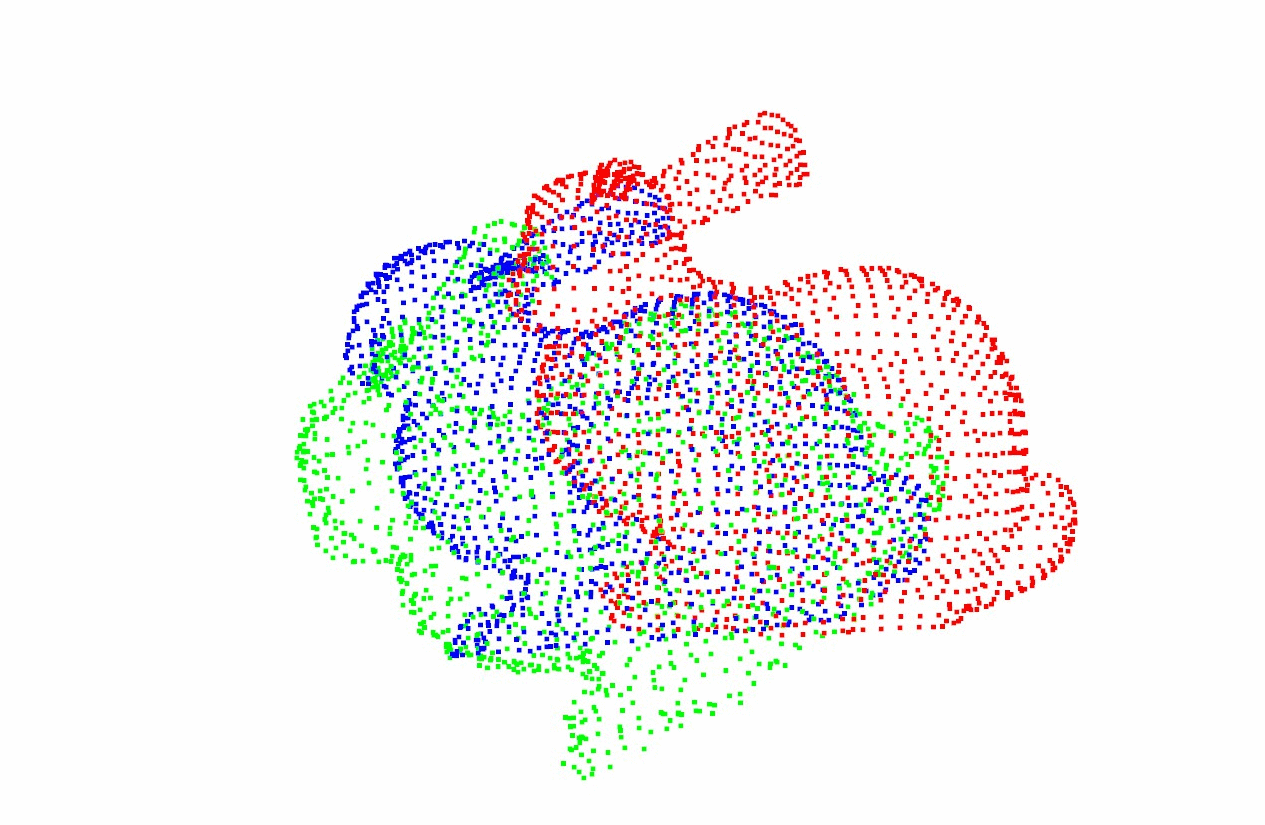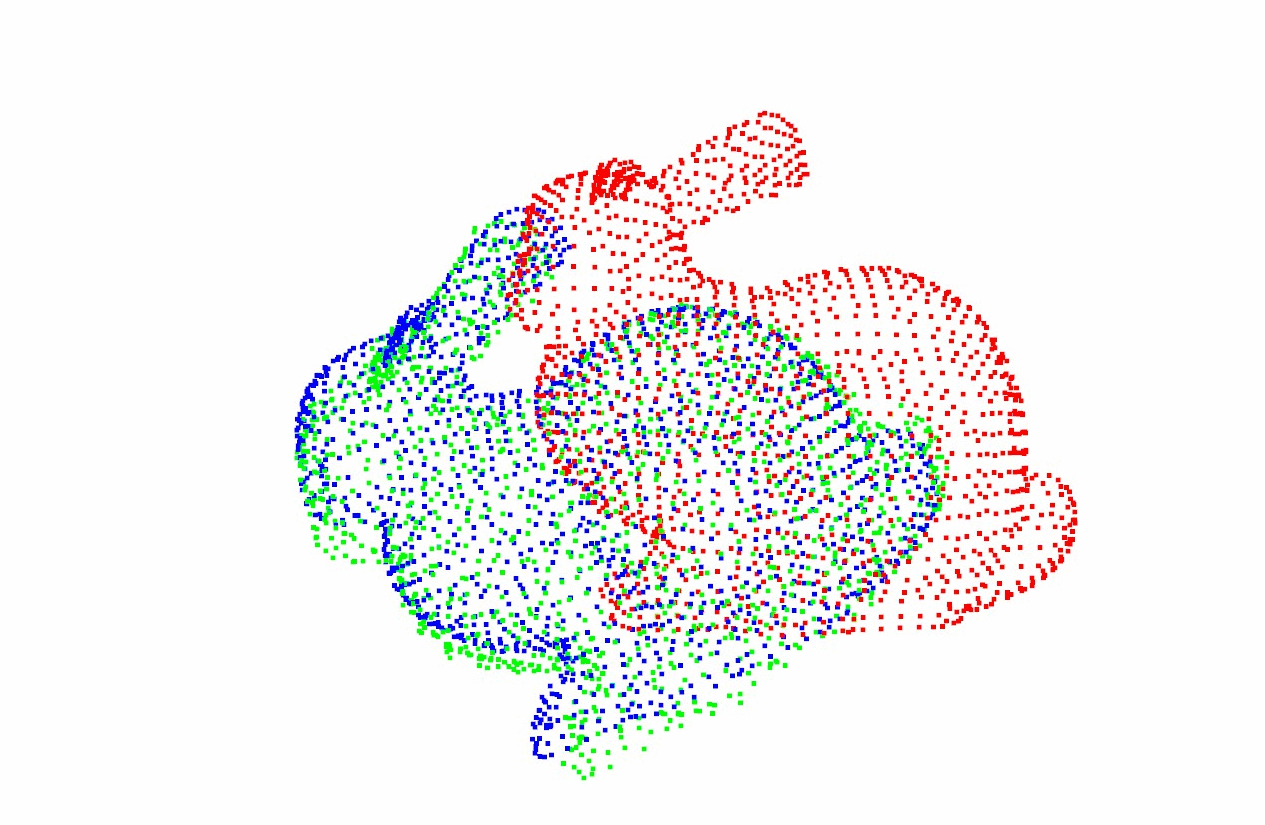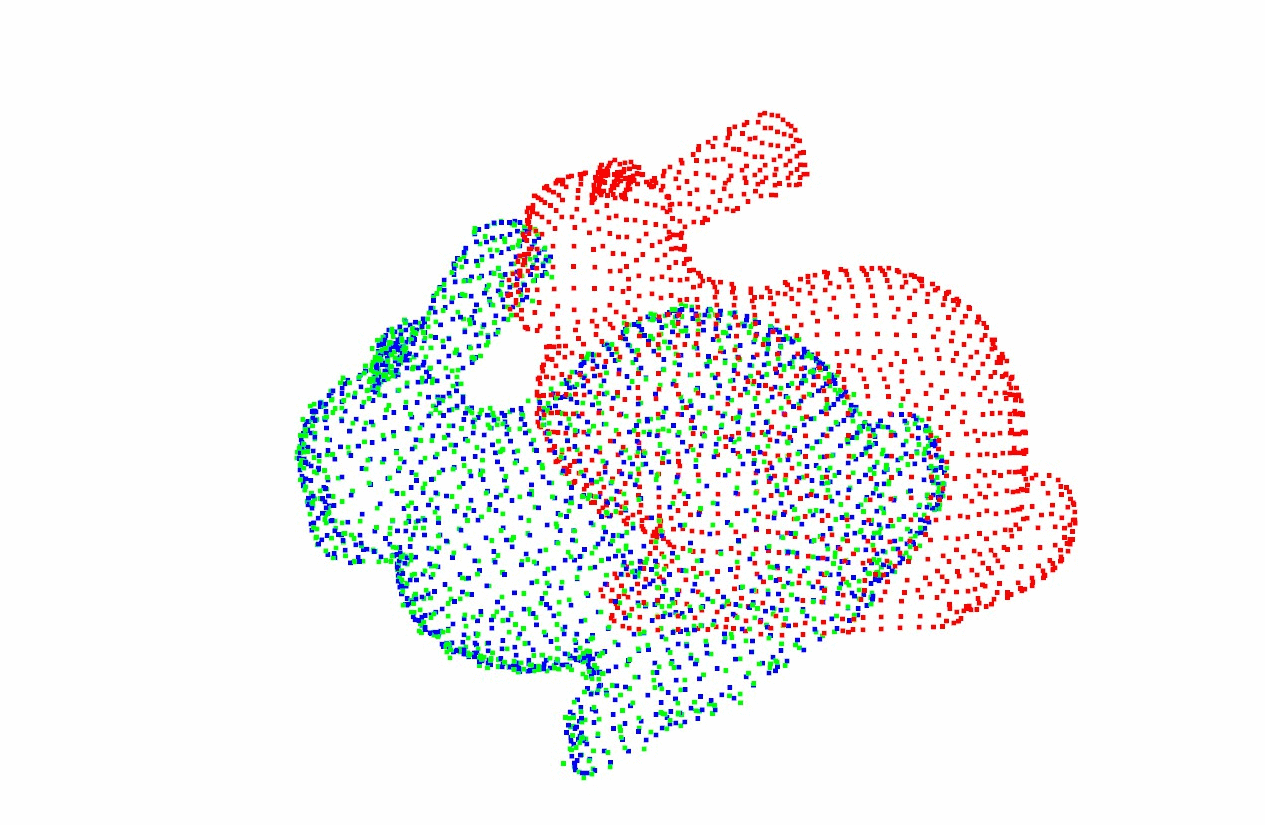 |
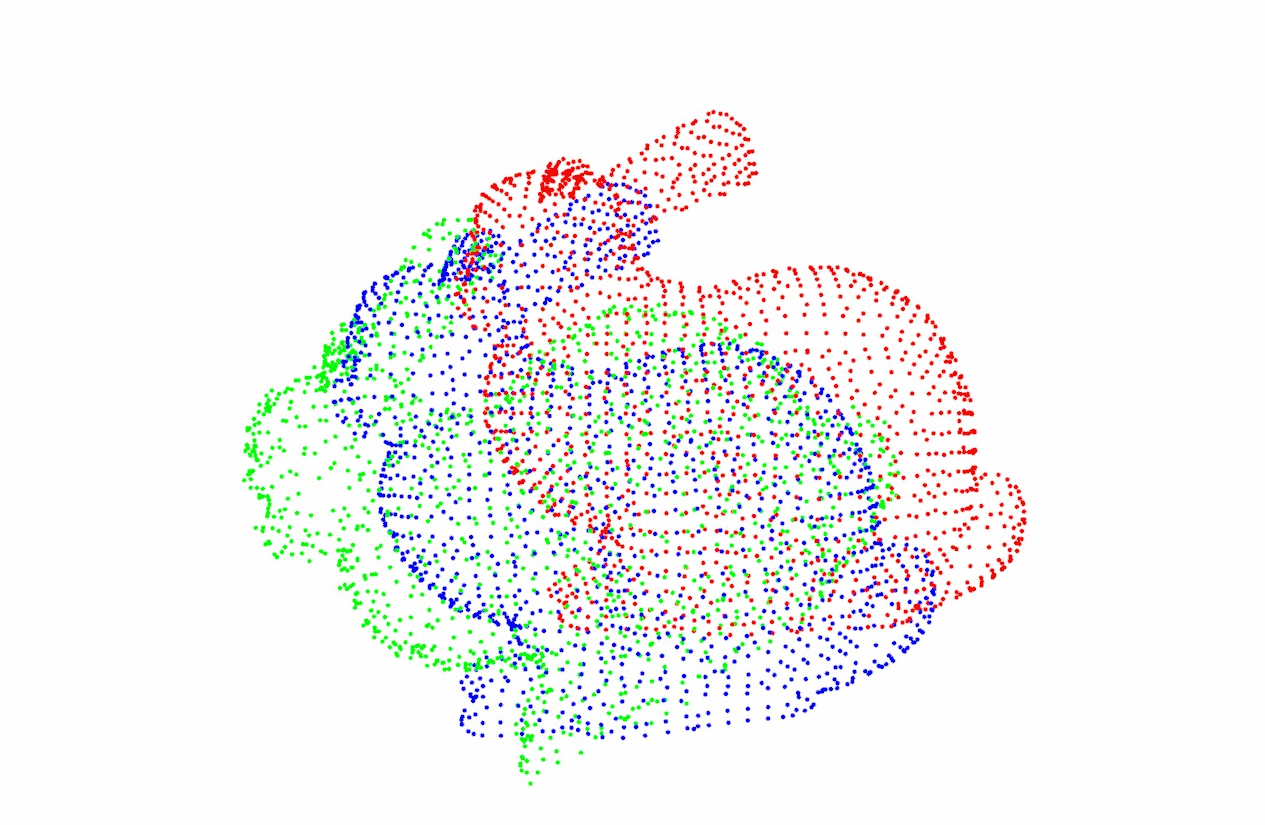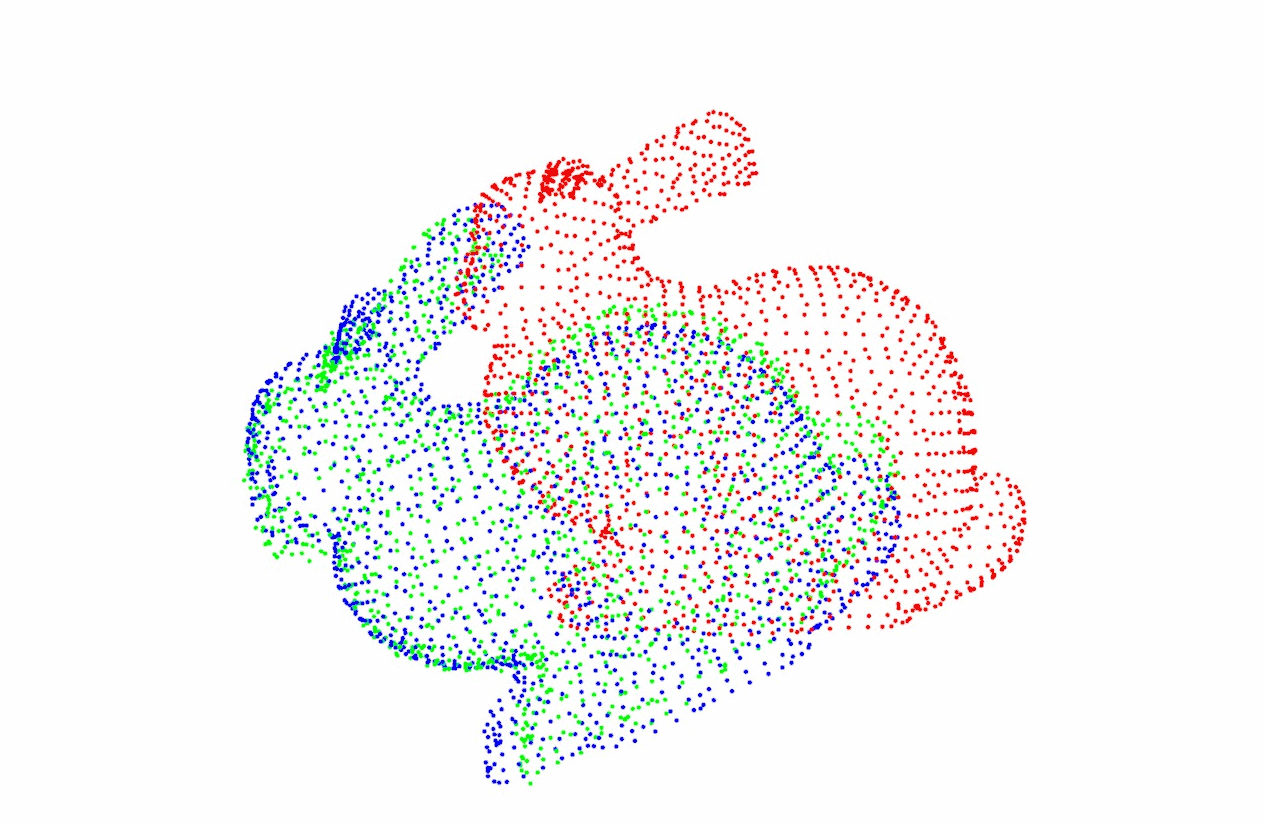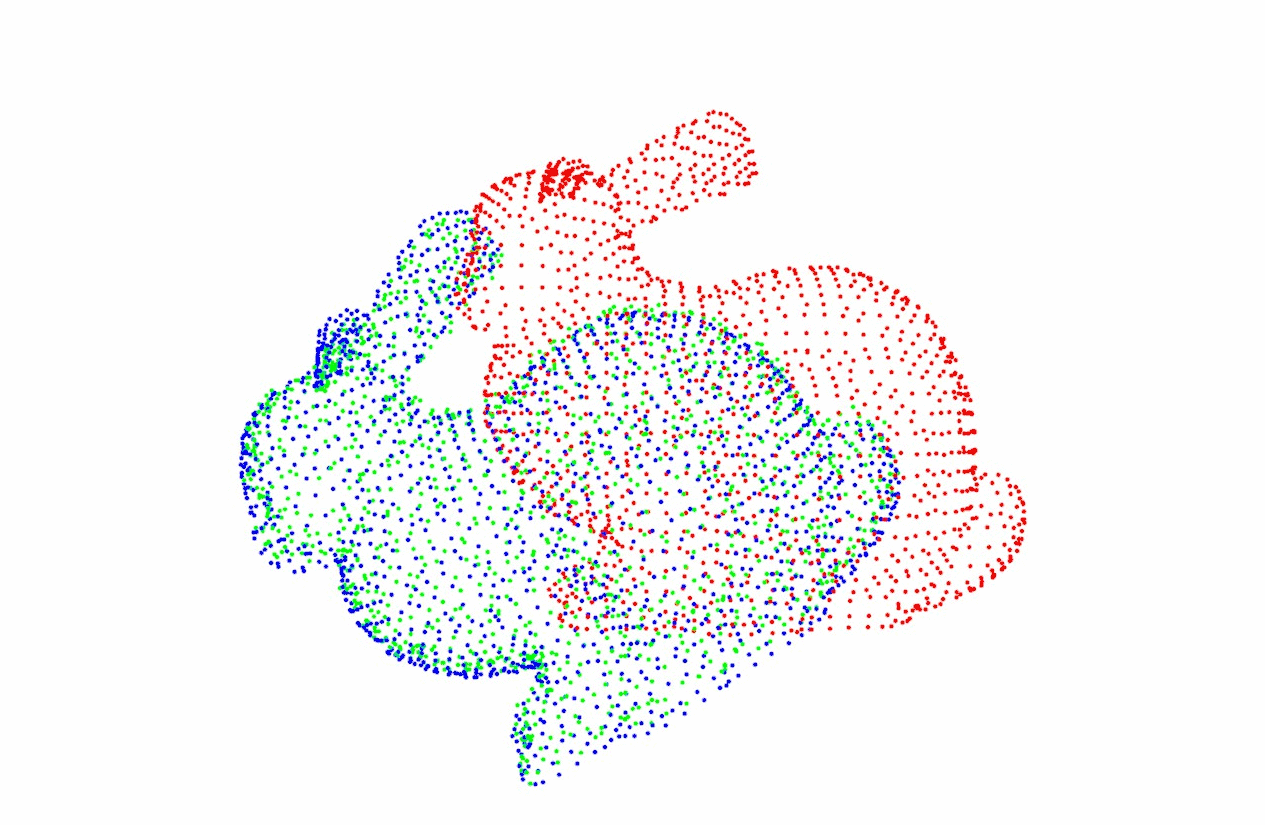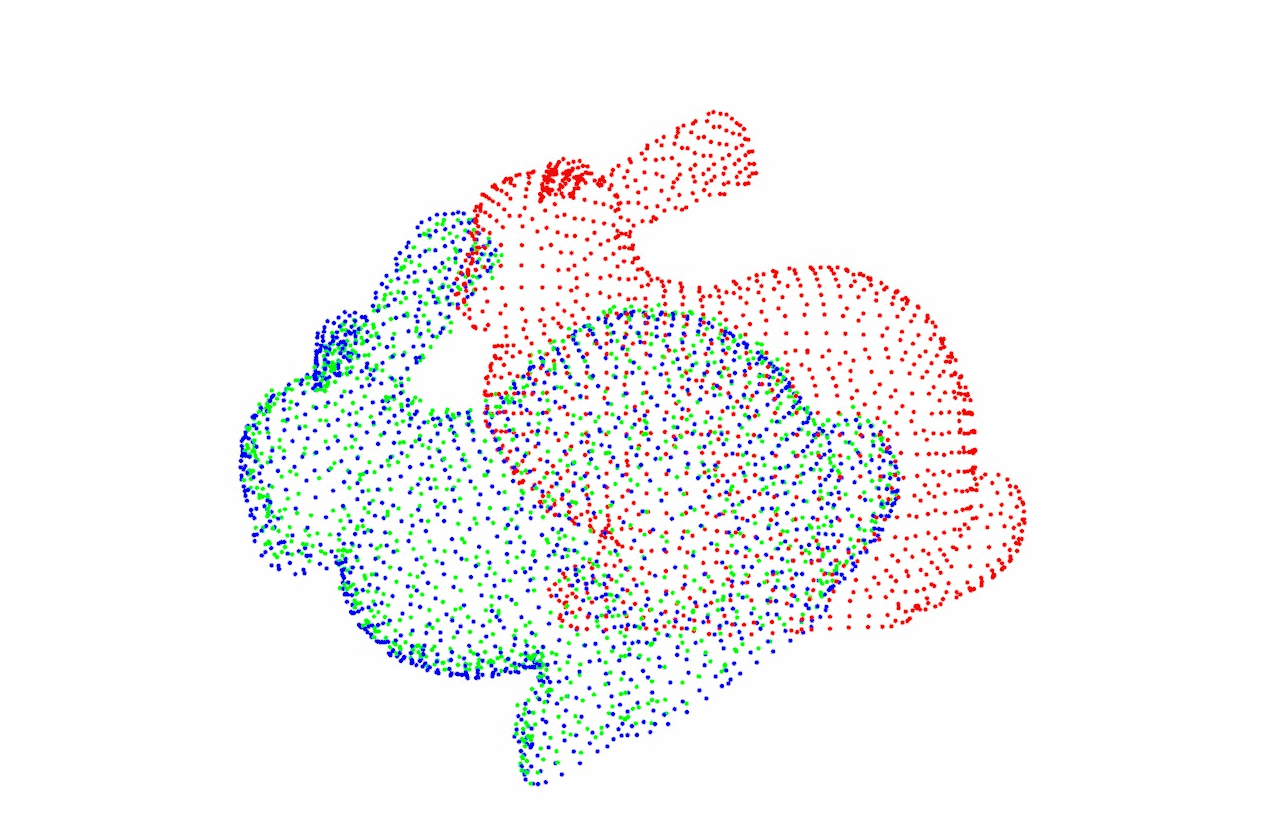 |
| ICP(Open3D) | CPD | FilterReg |
|---|---|---|
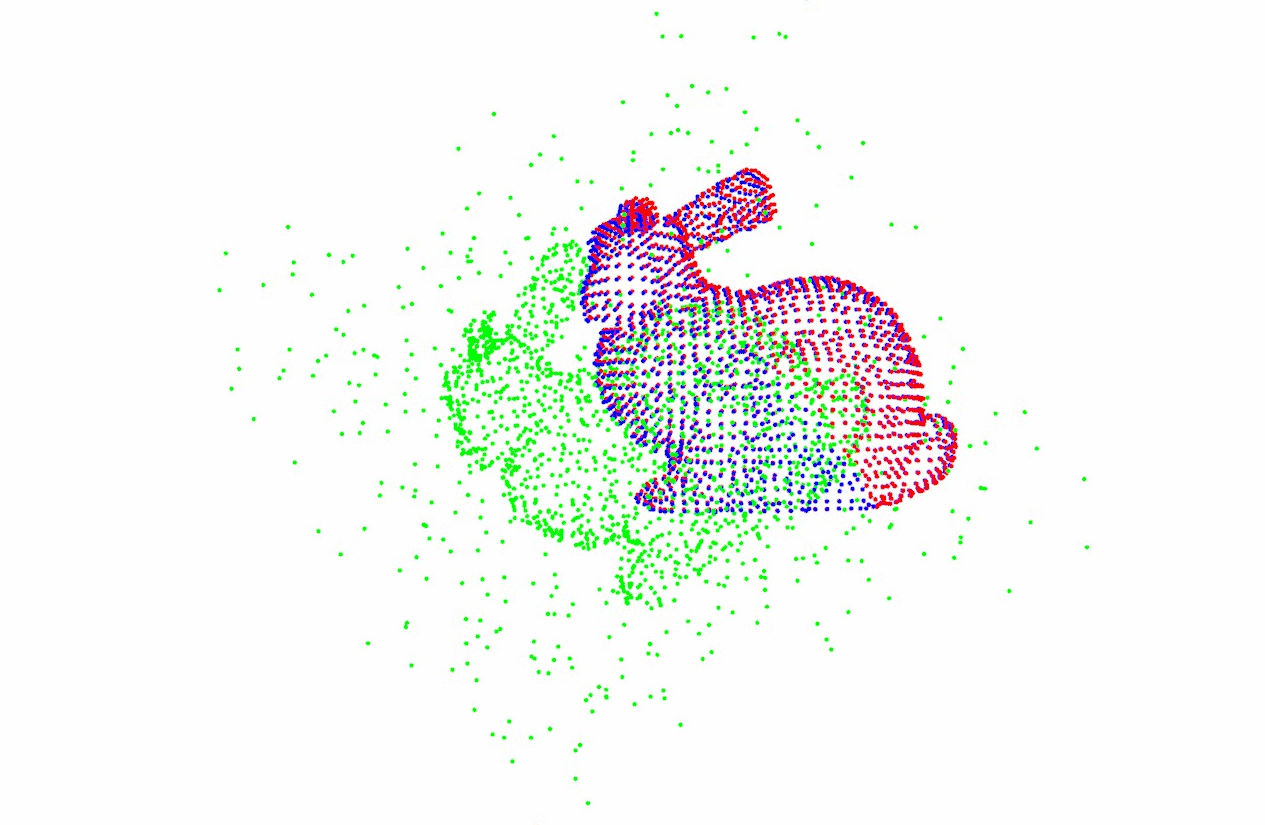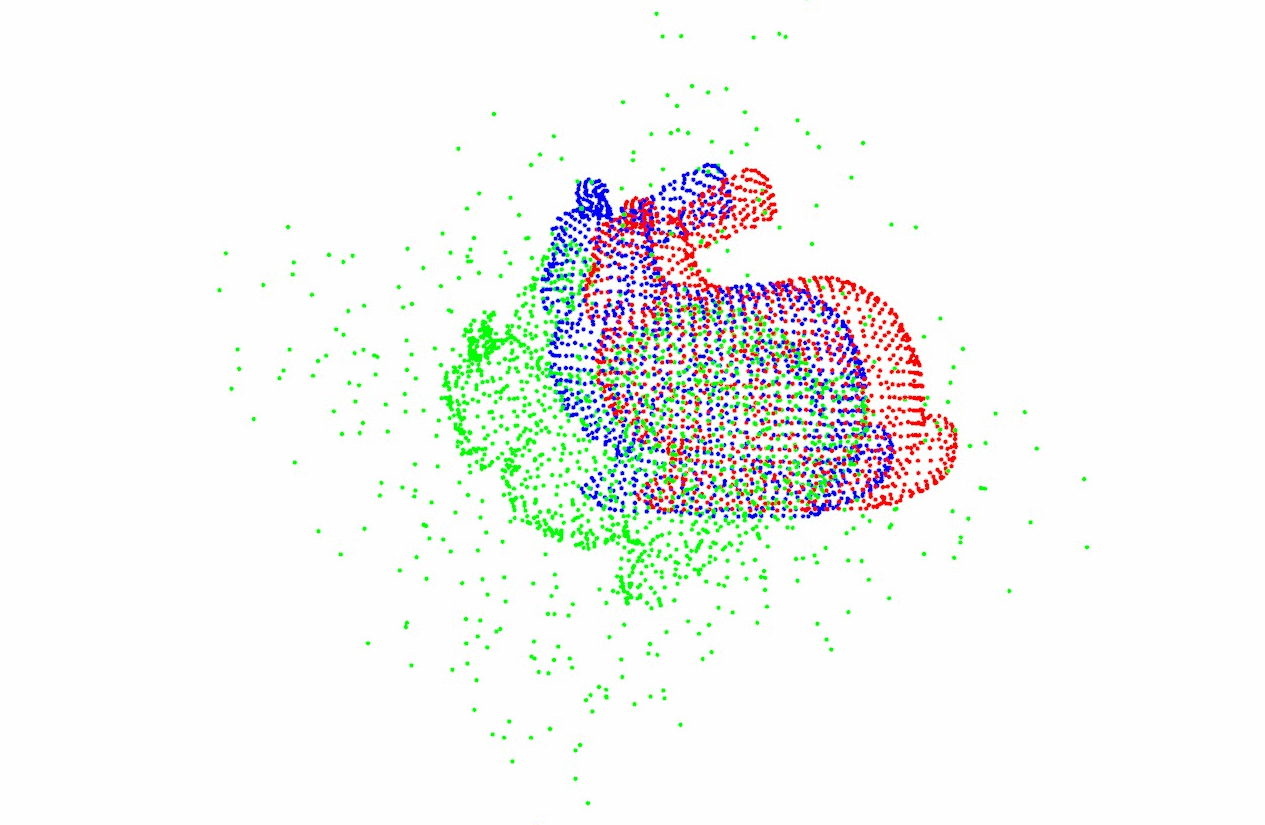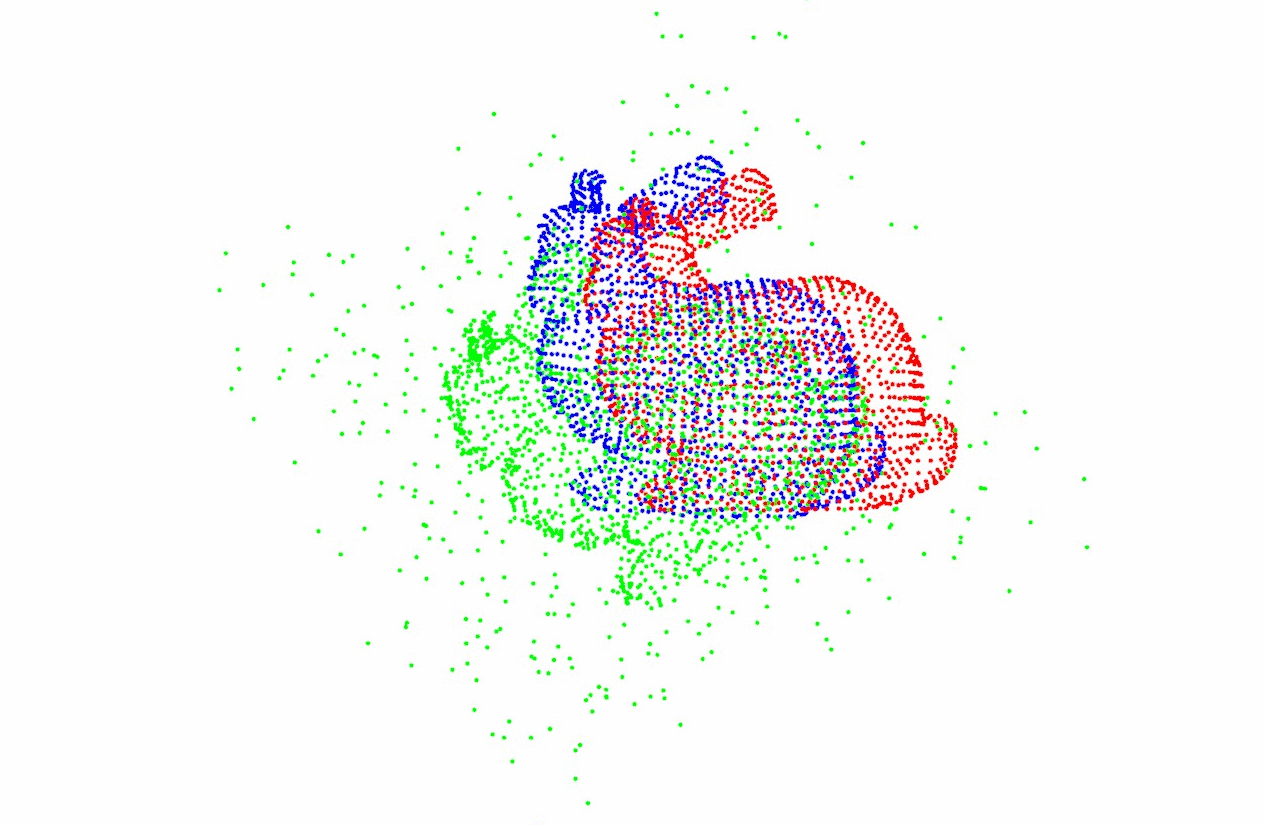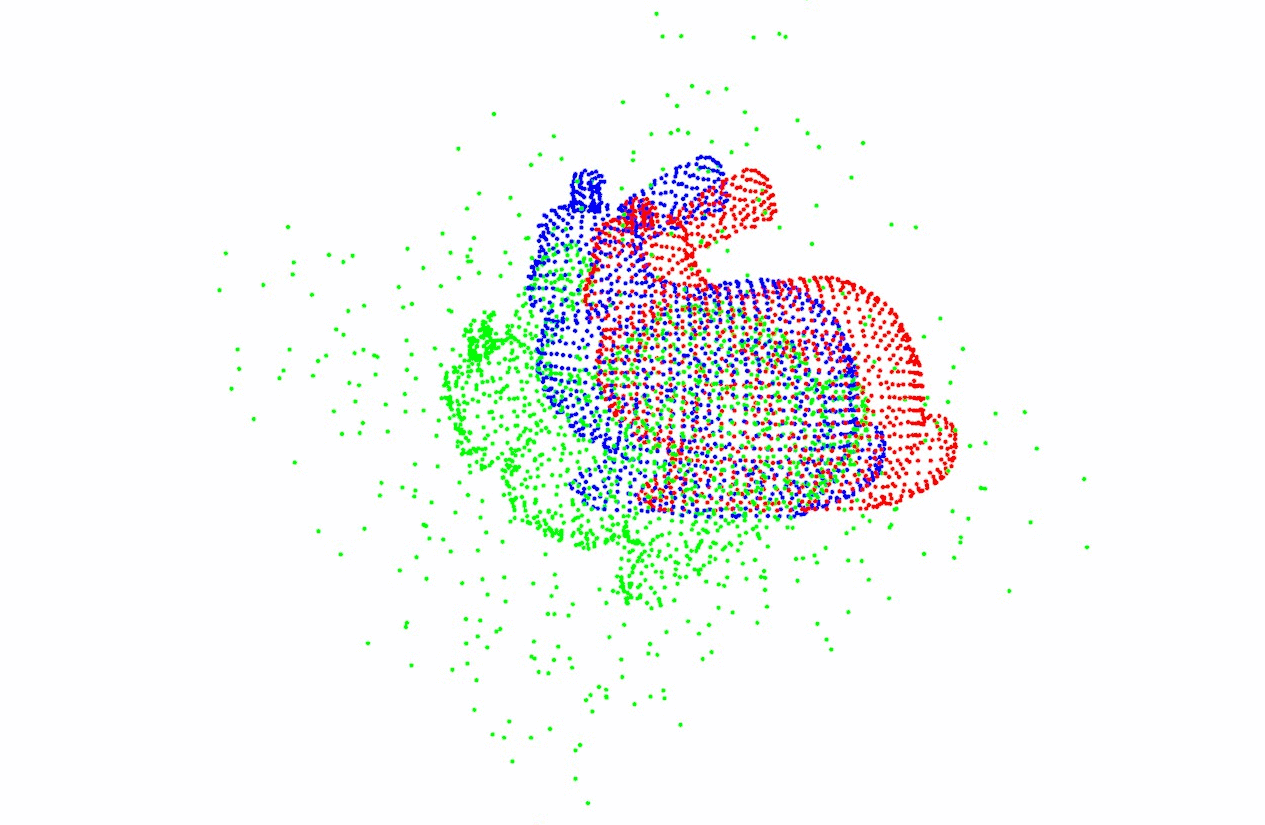 |
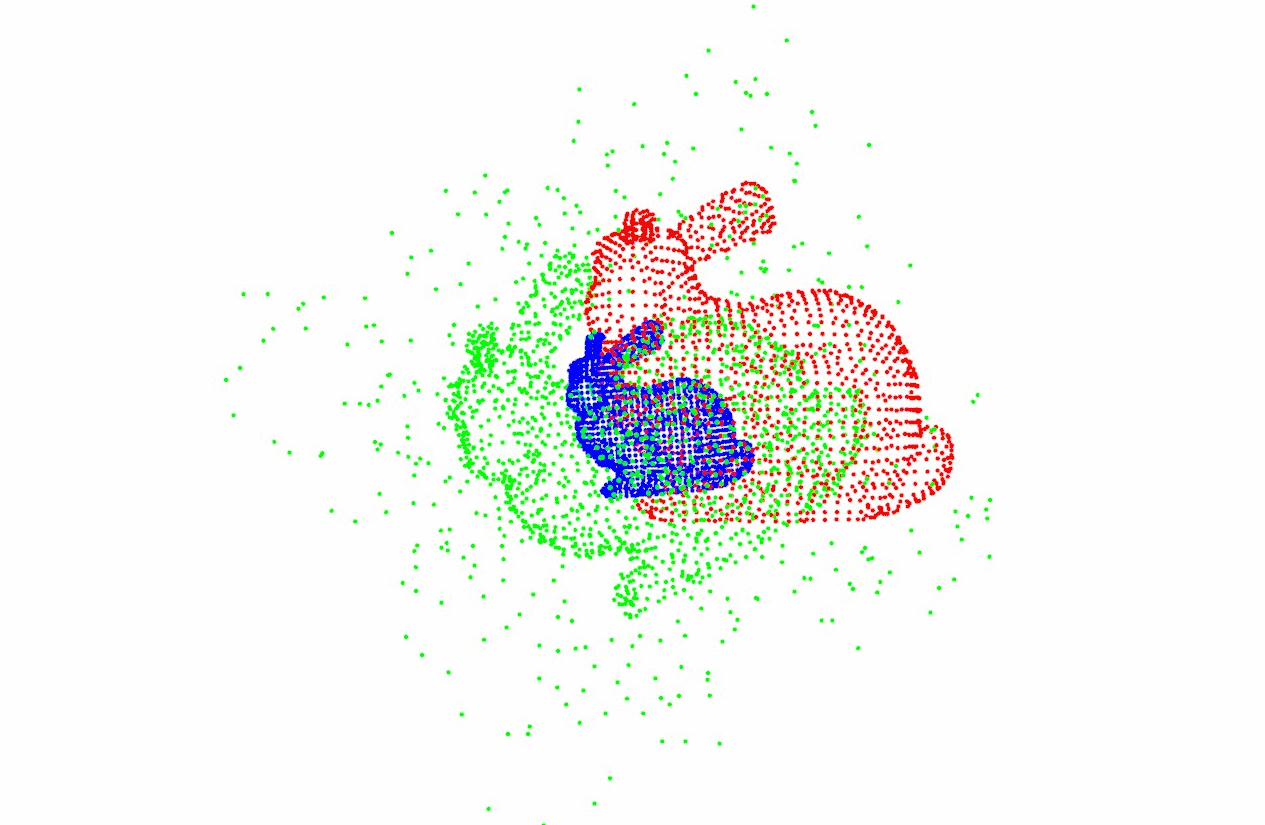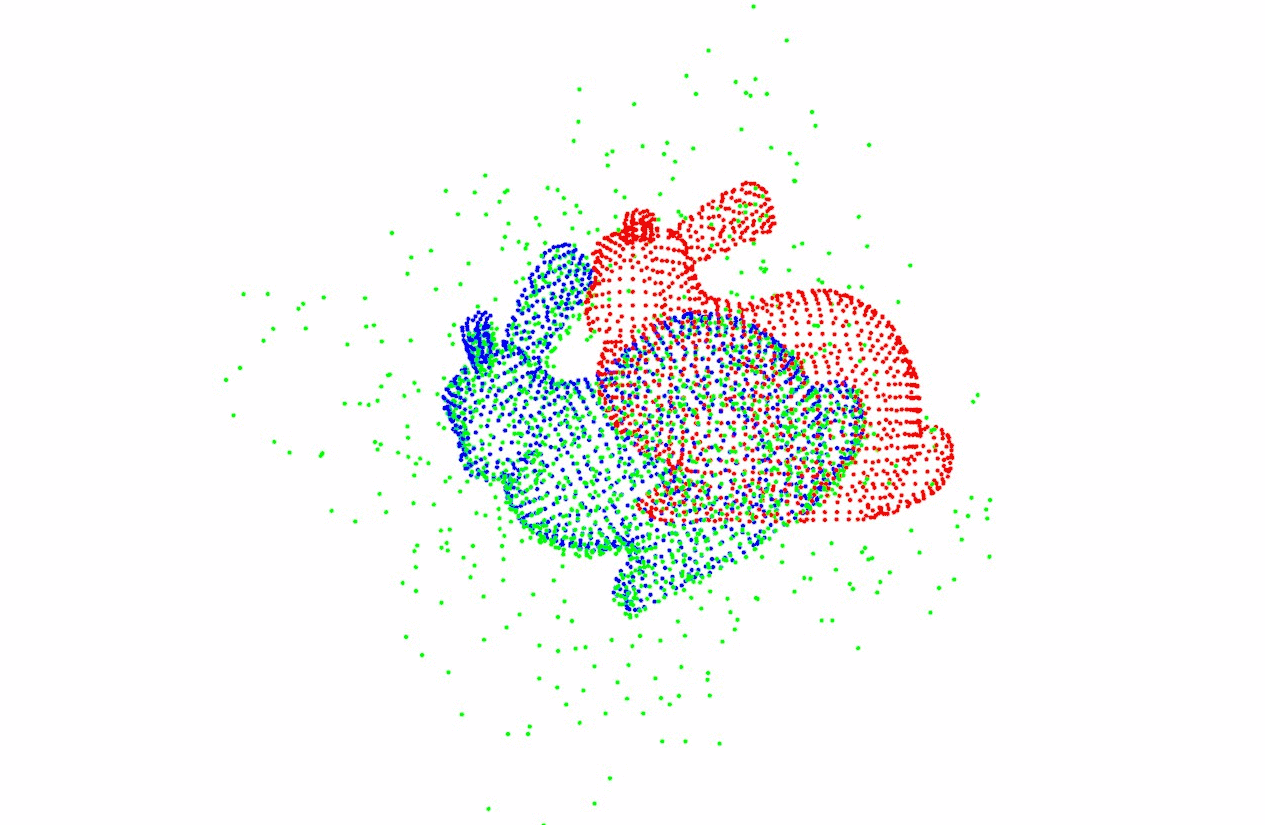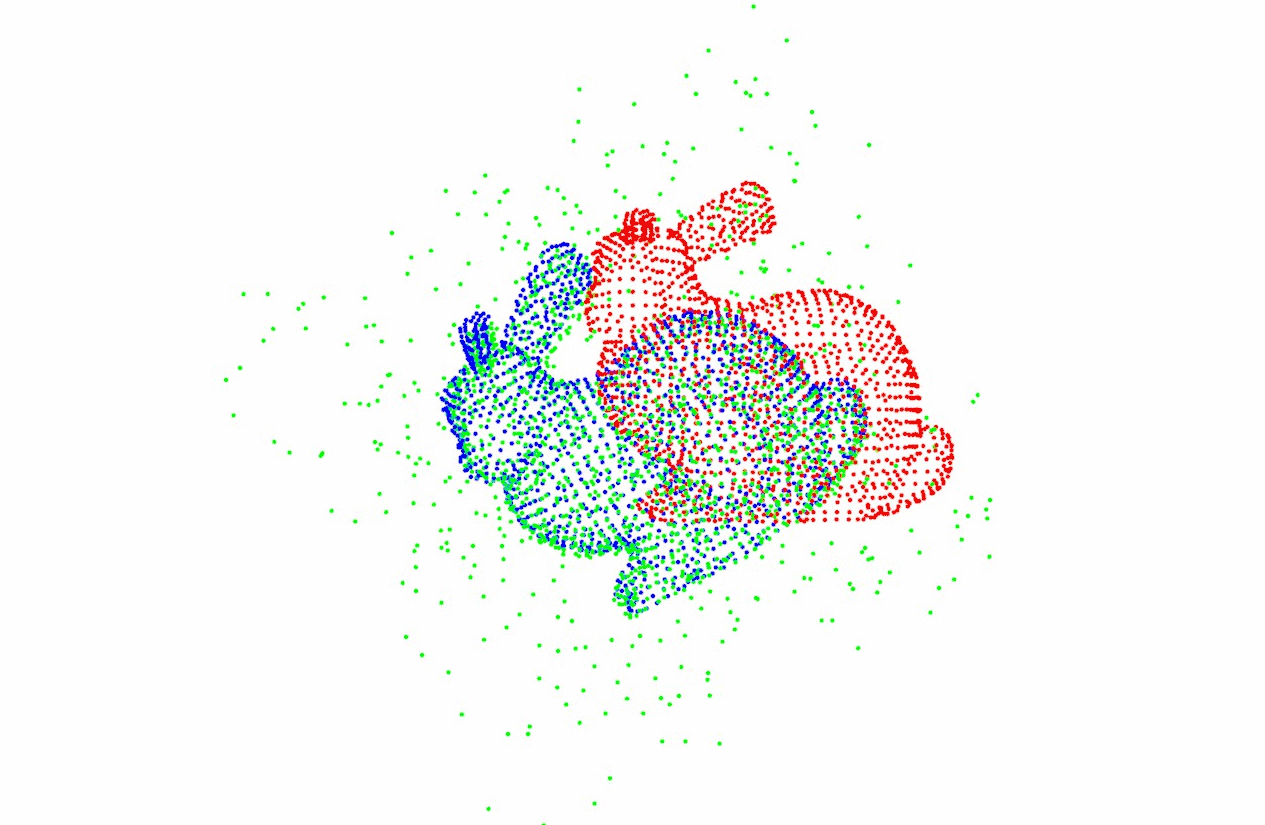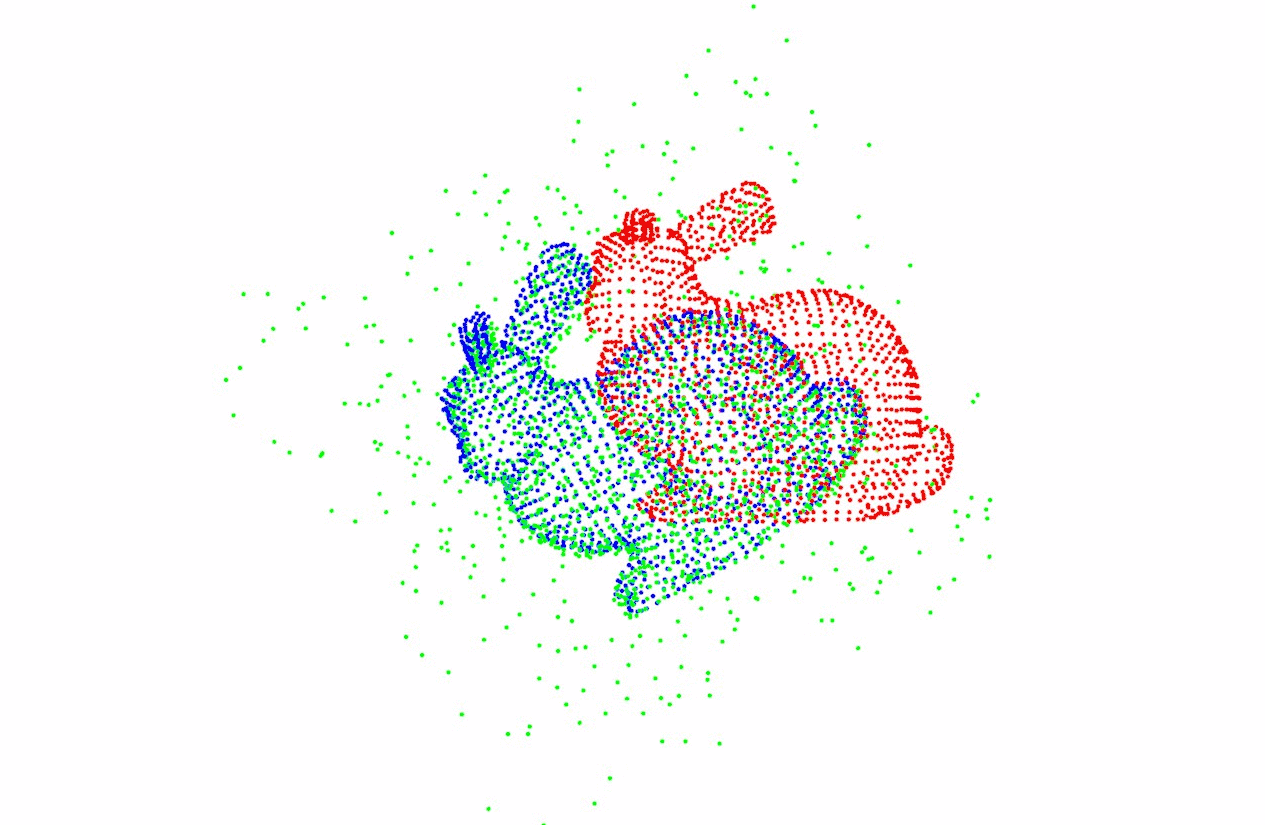 |
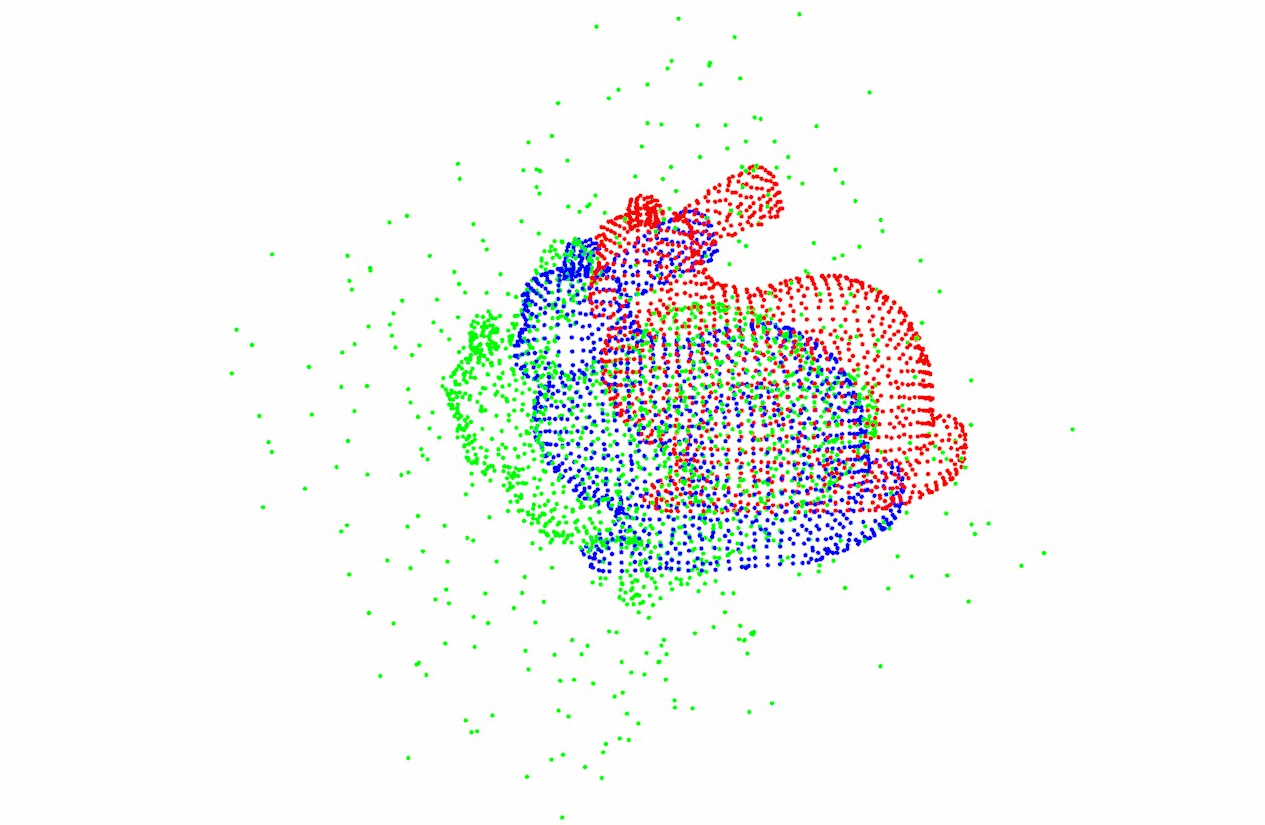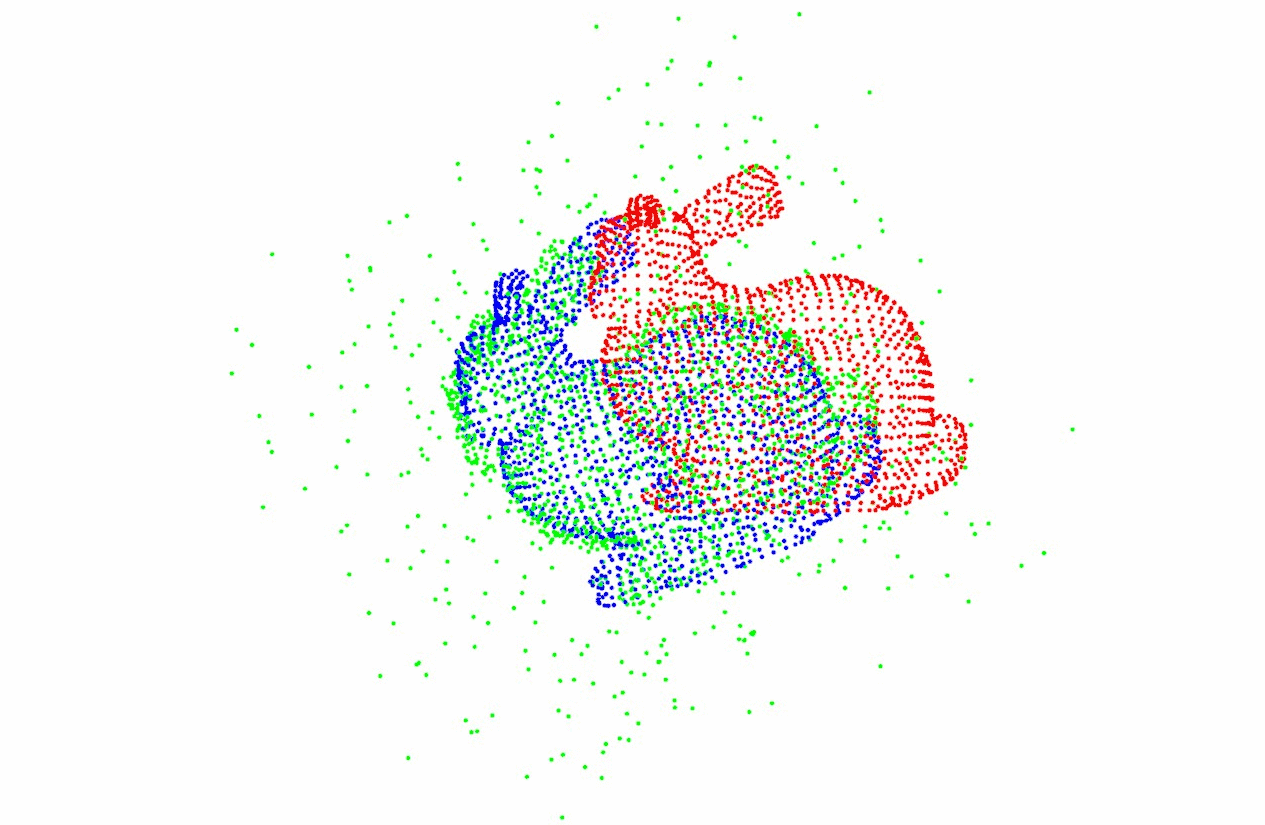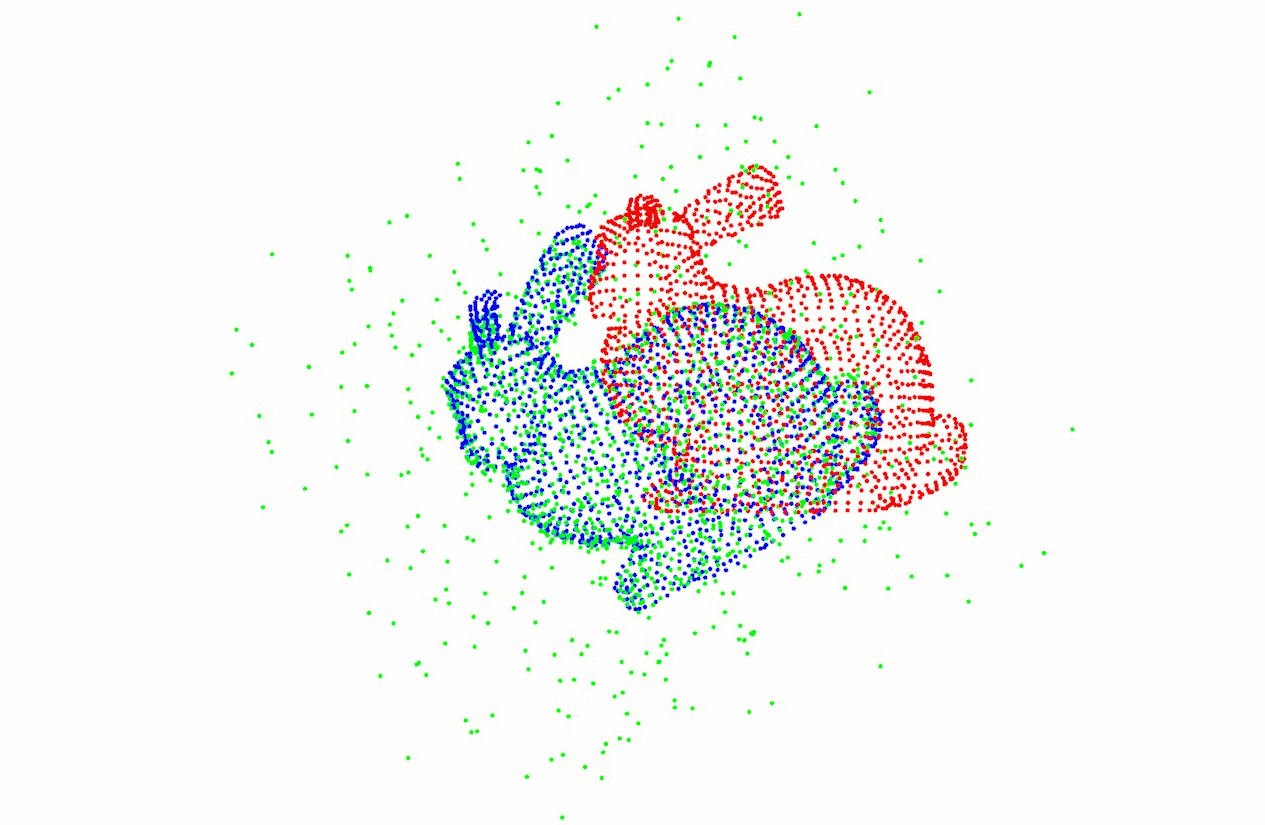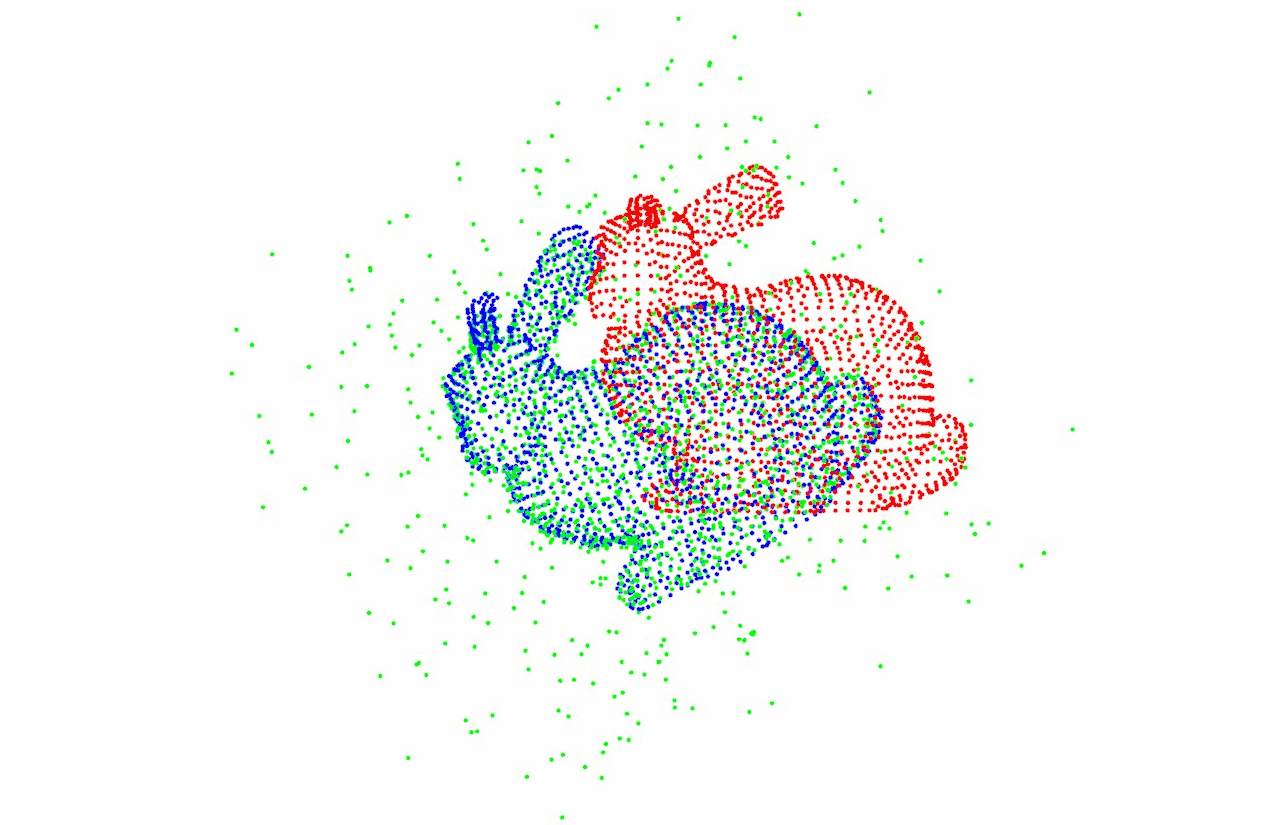 |
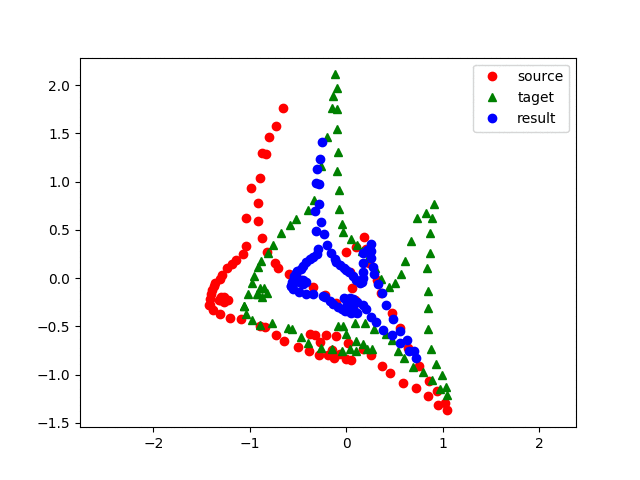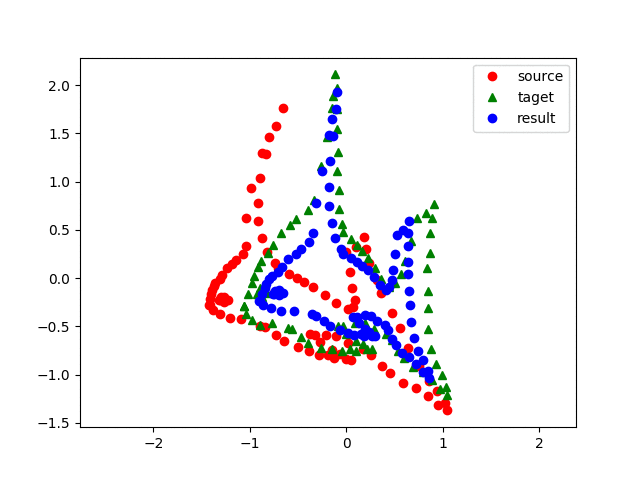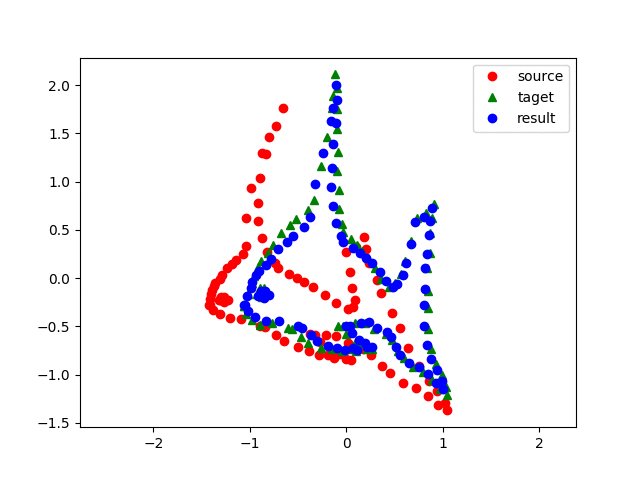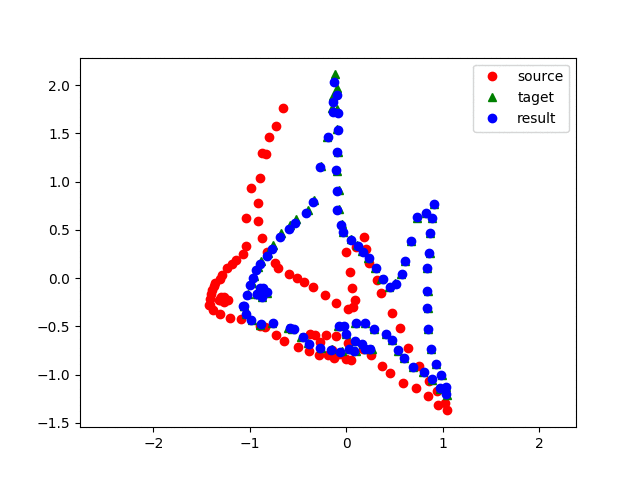
| CPD | SVR | Filterreg | BCPD |
|---|---|---|---|
 |
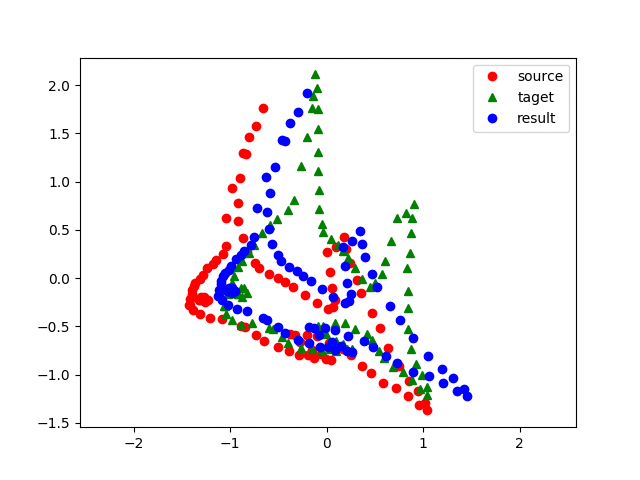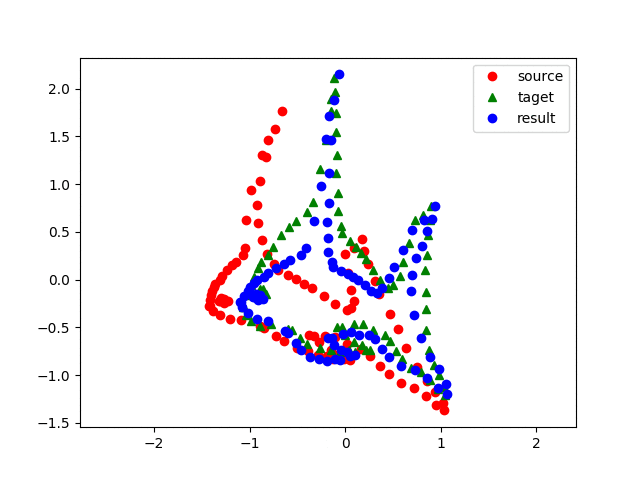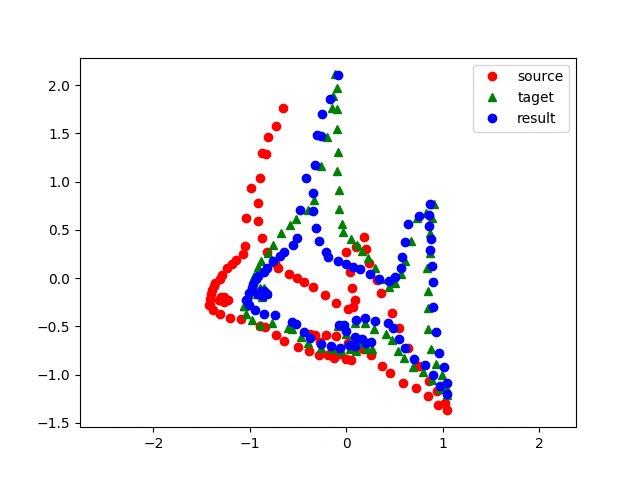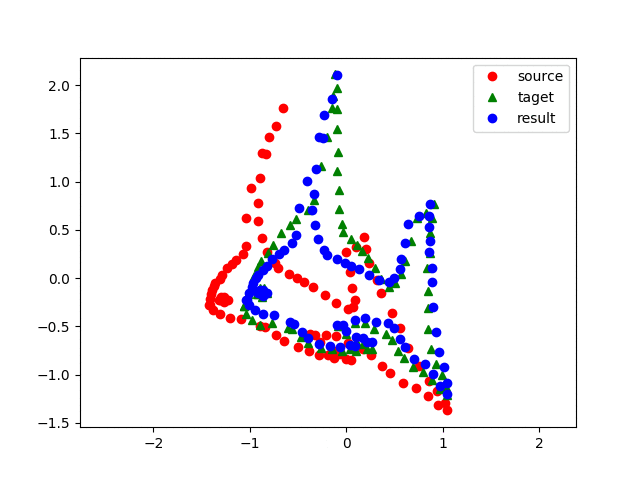 |
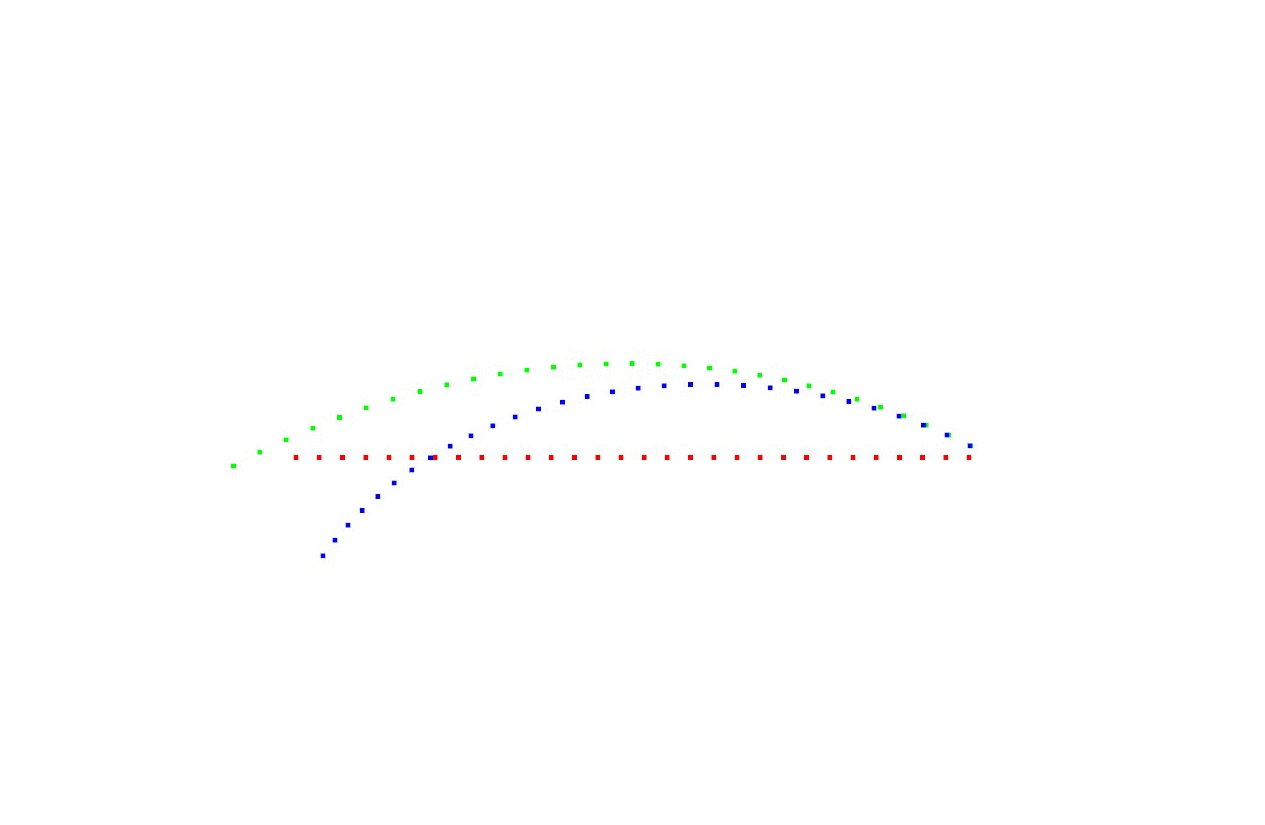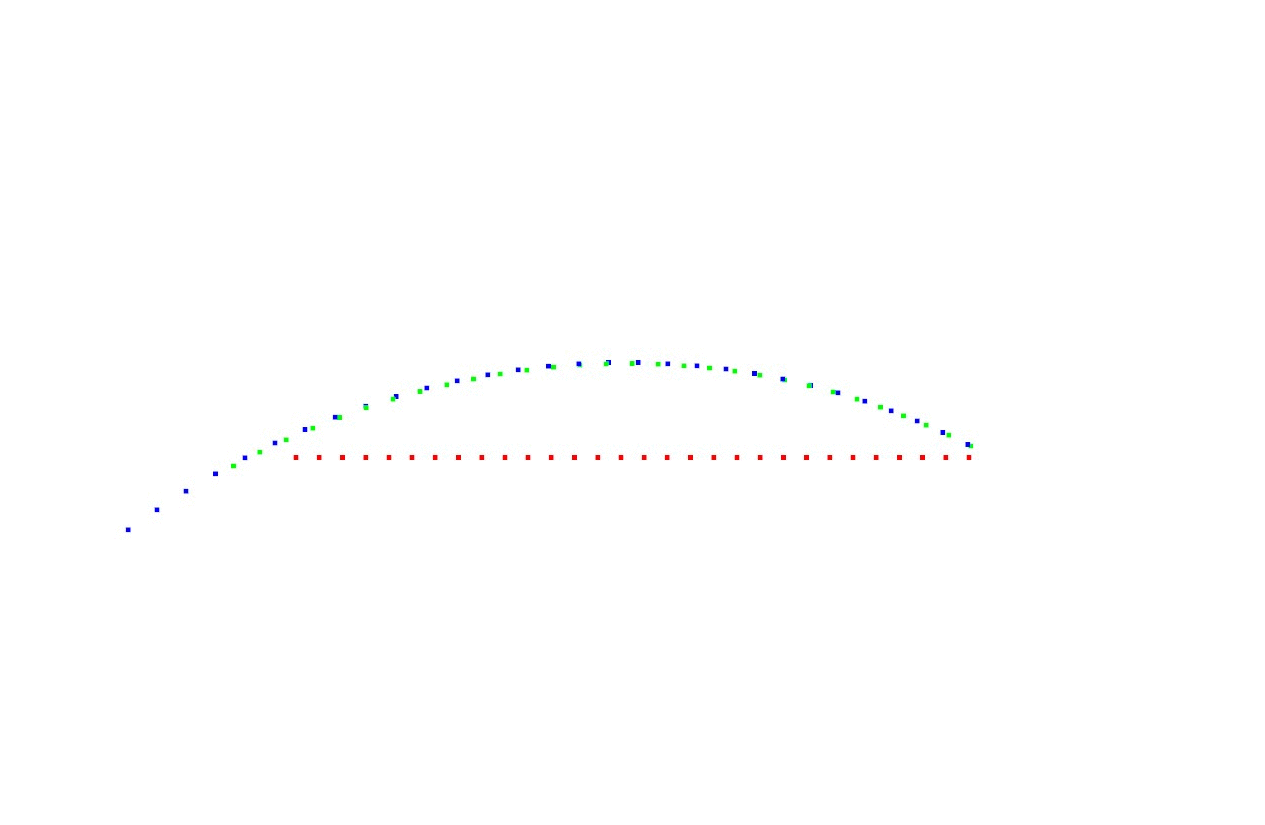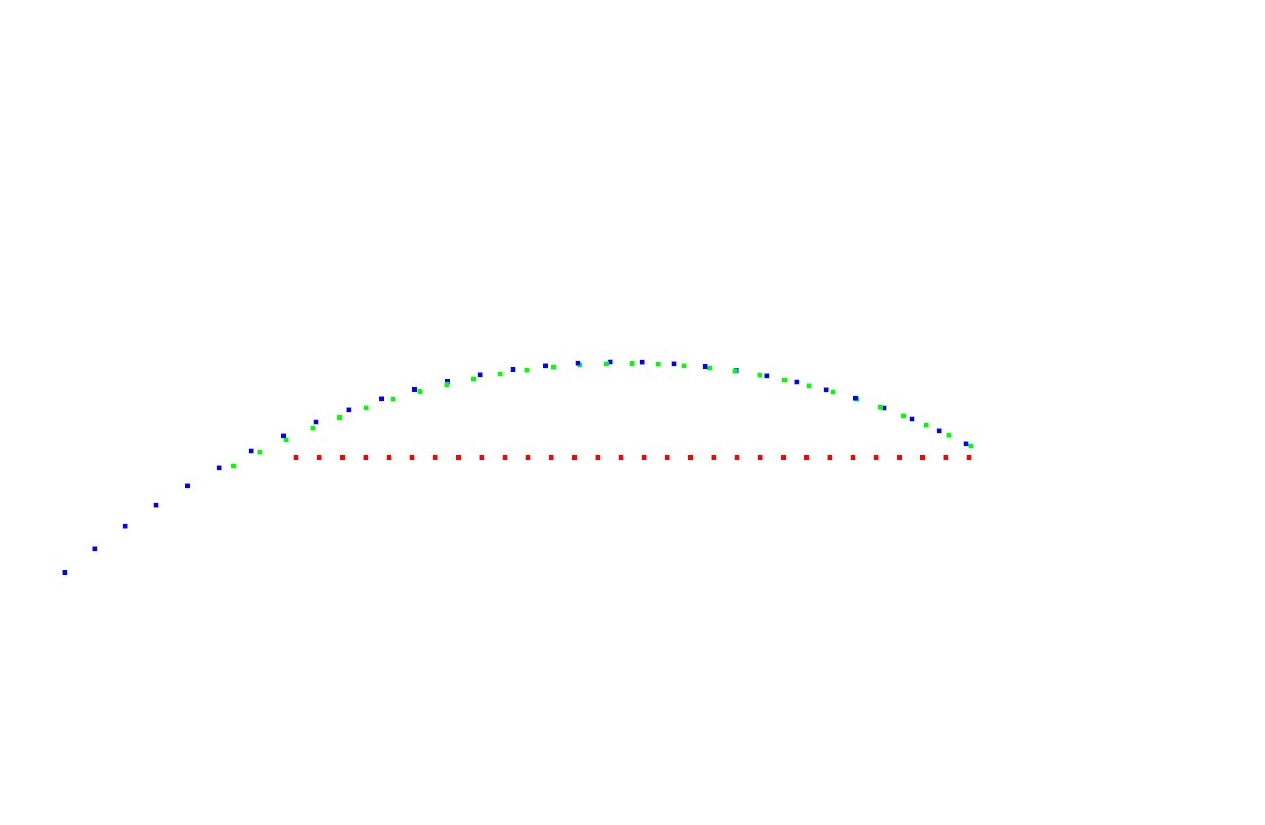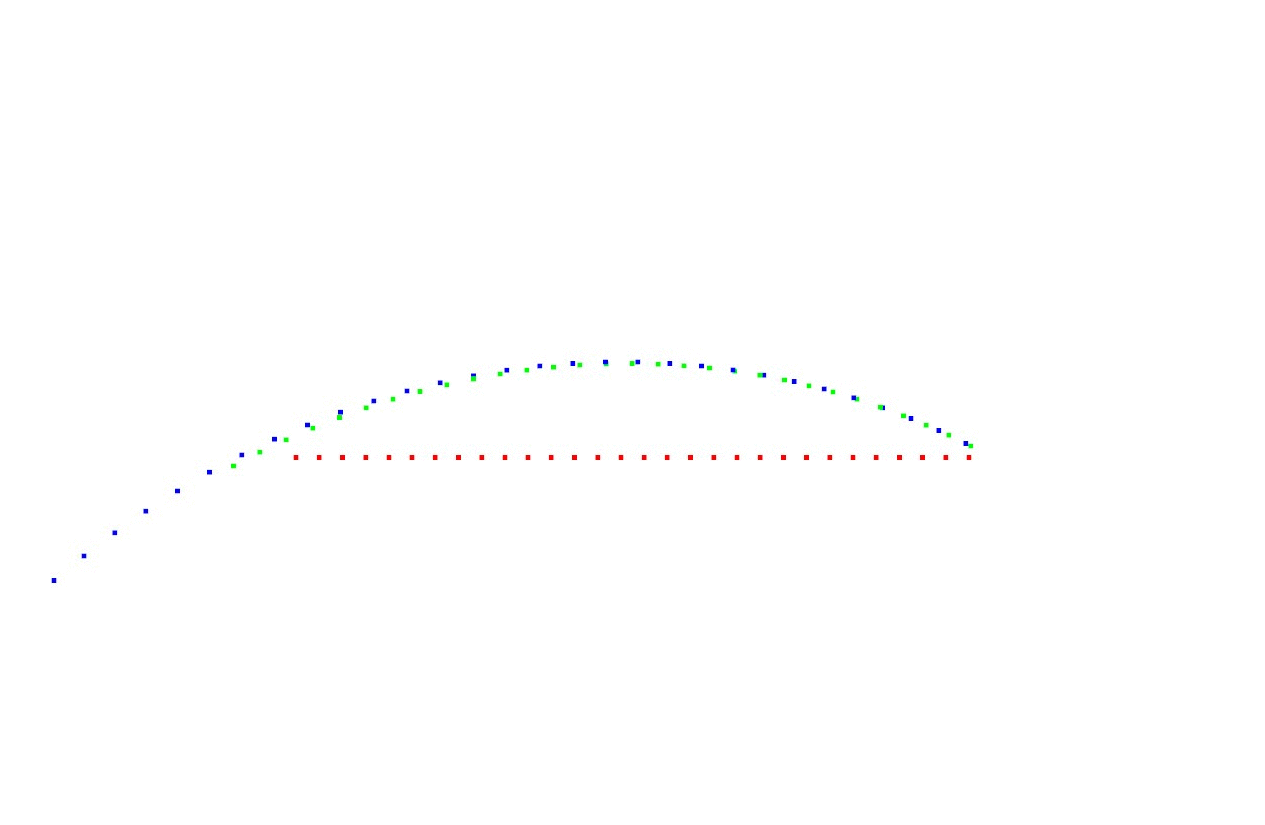 |
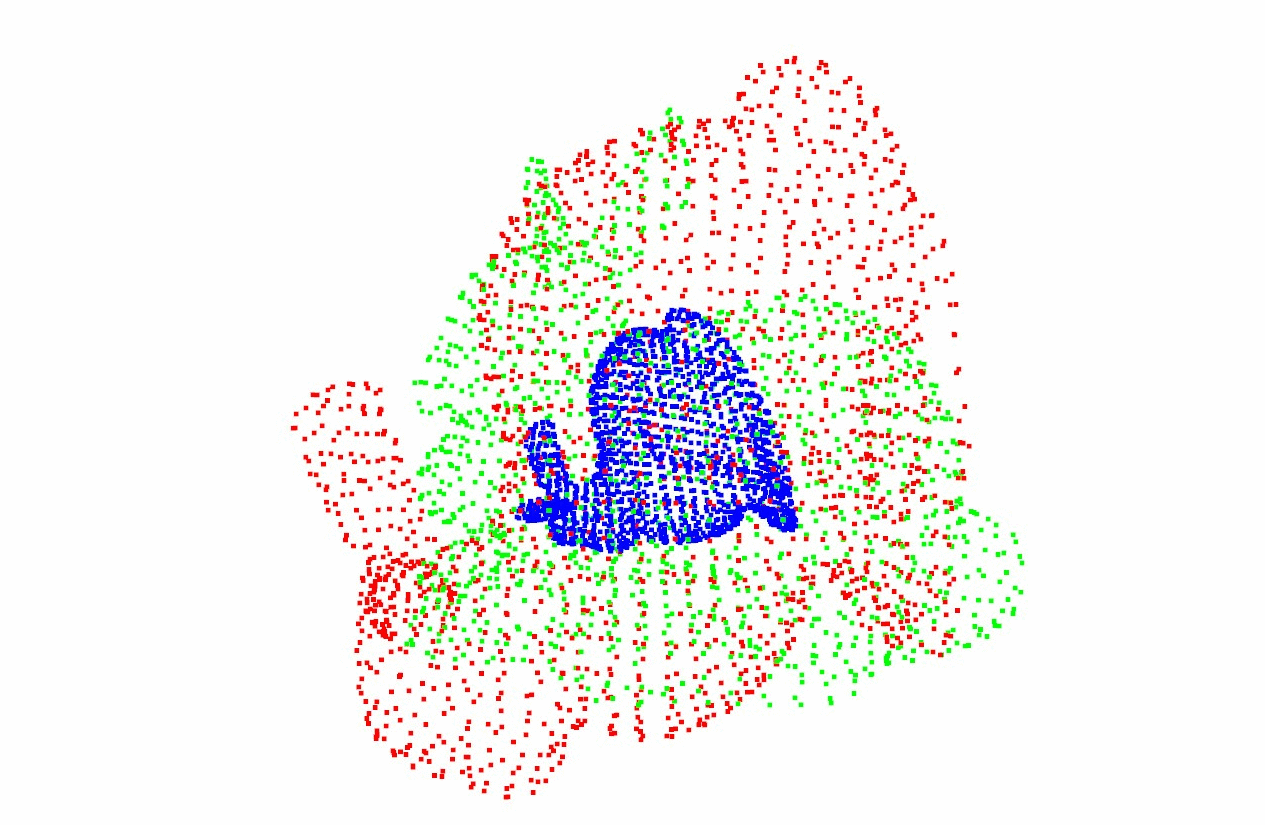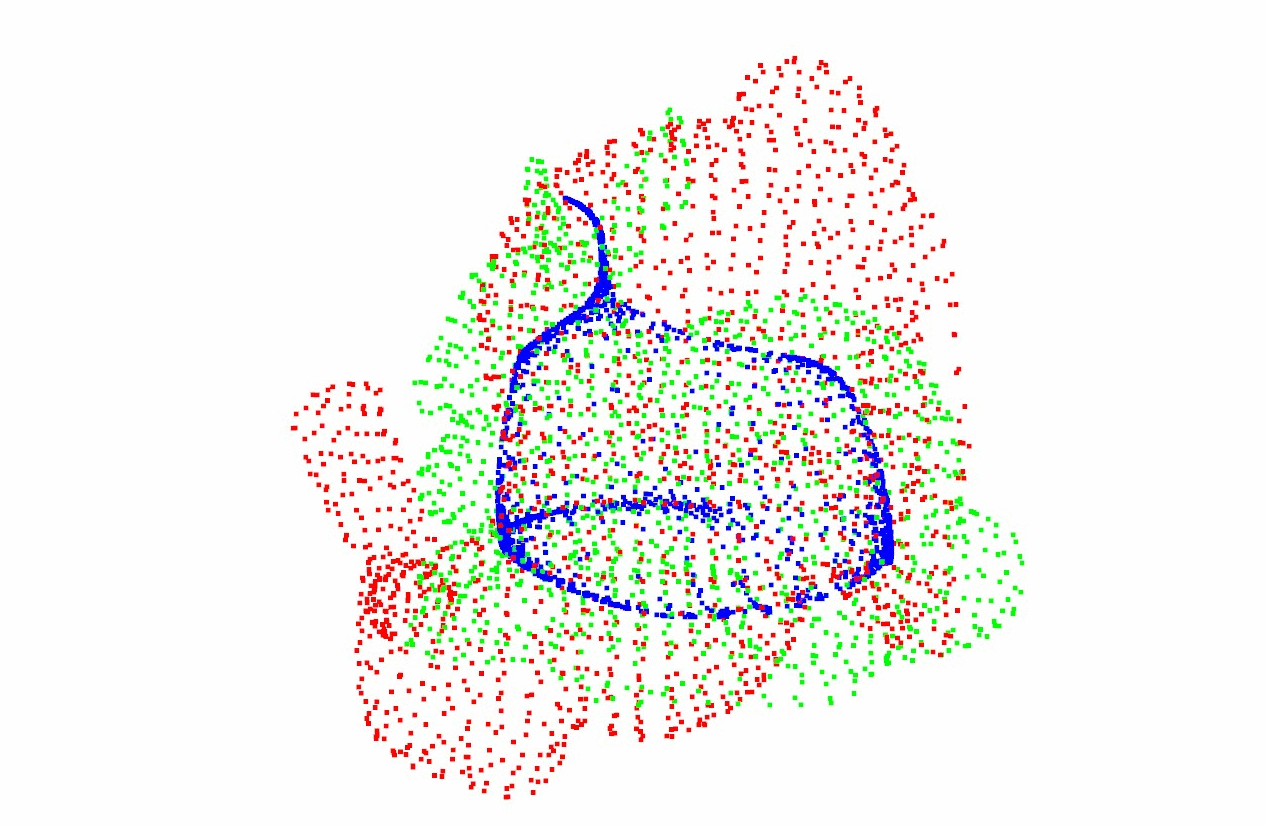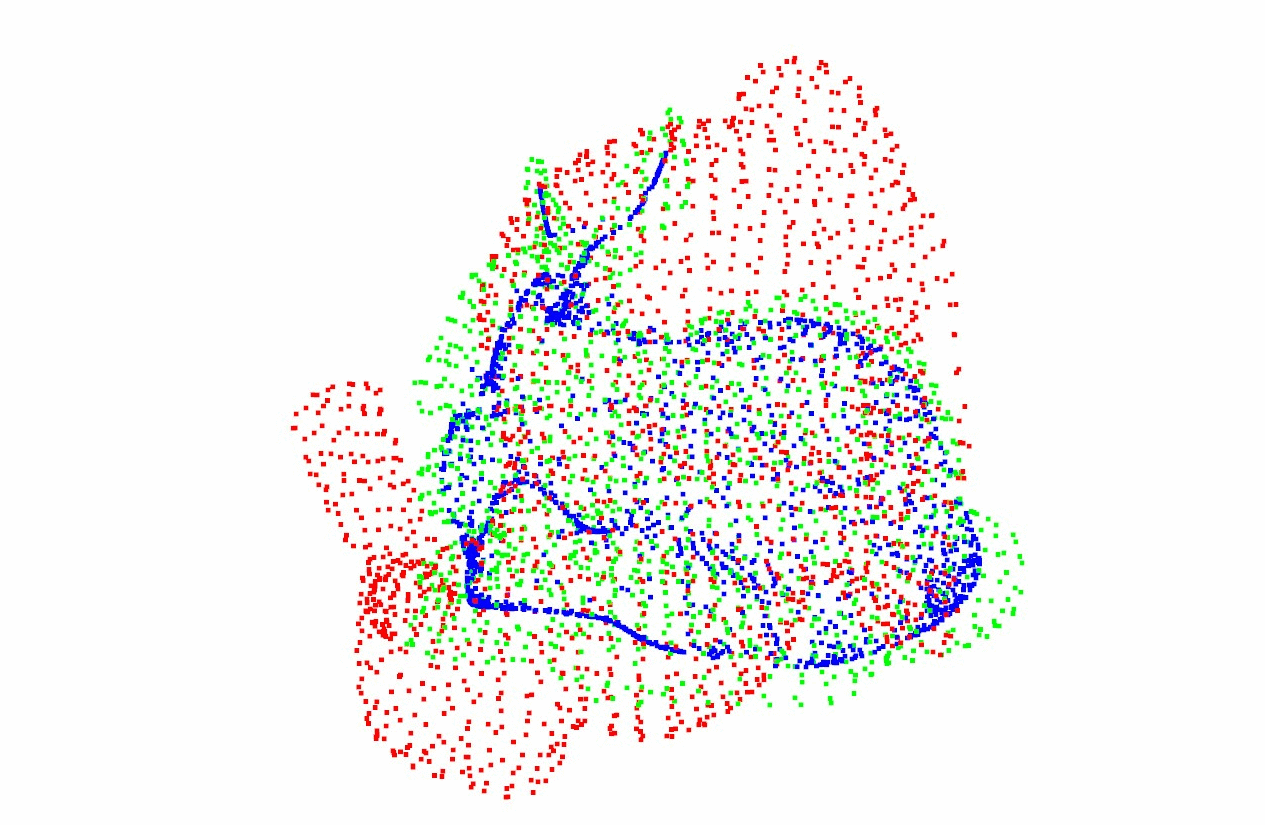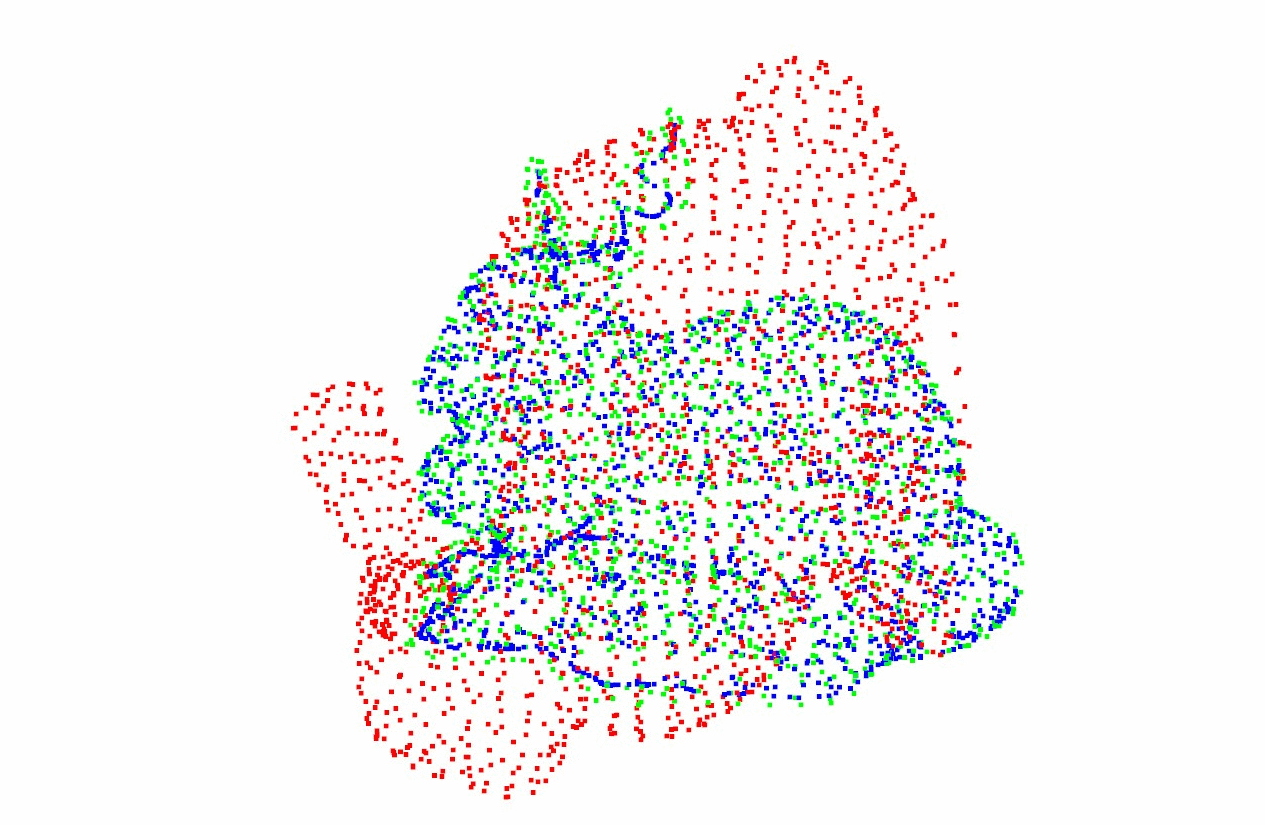 |
| FPFH FilterReg |
|---|
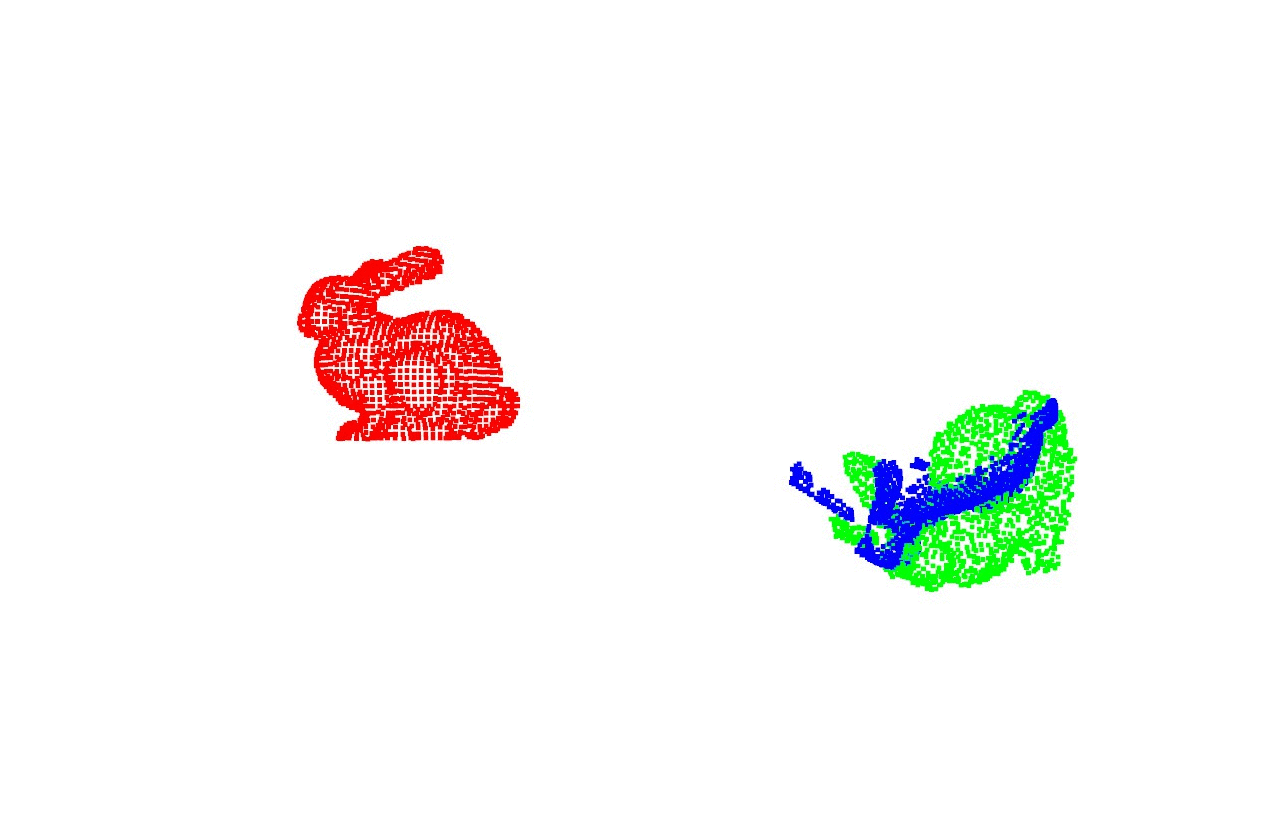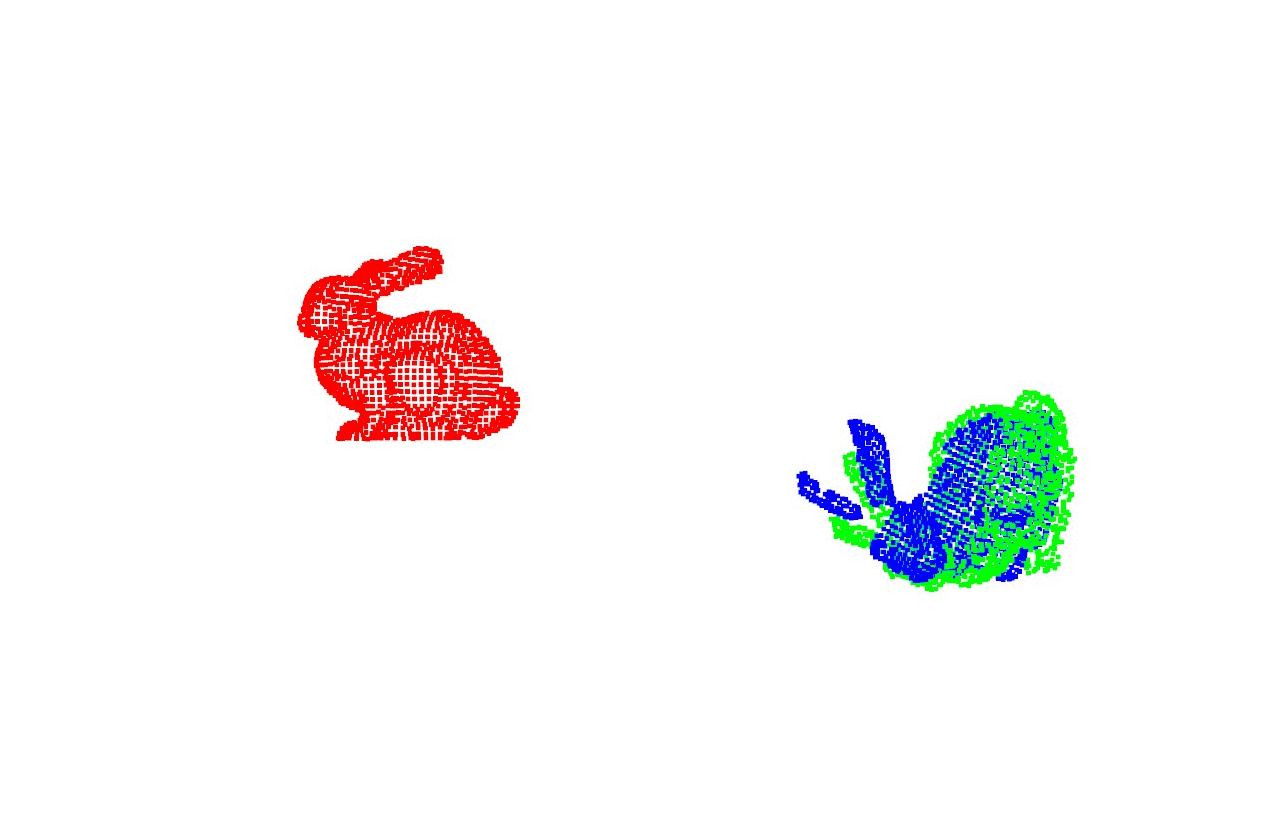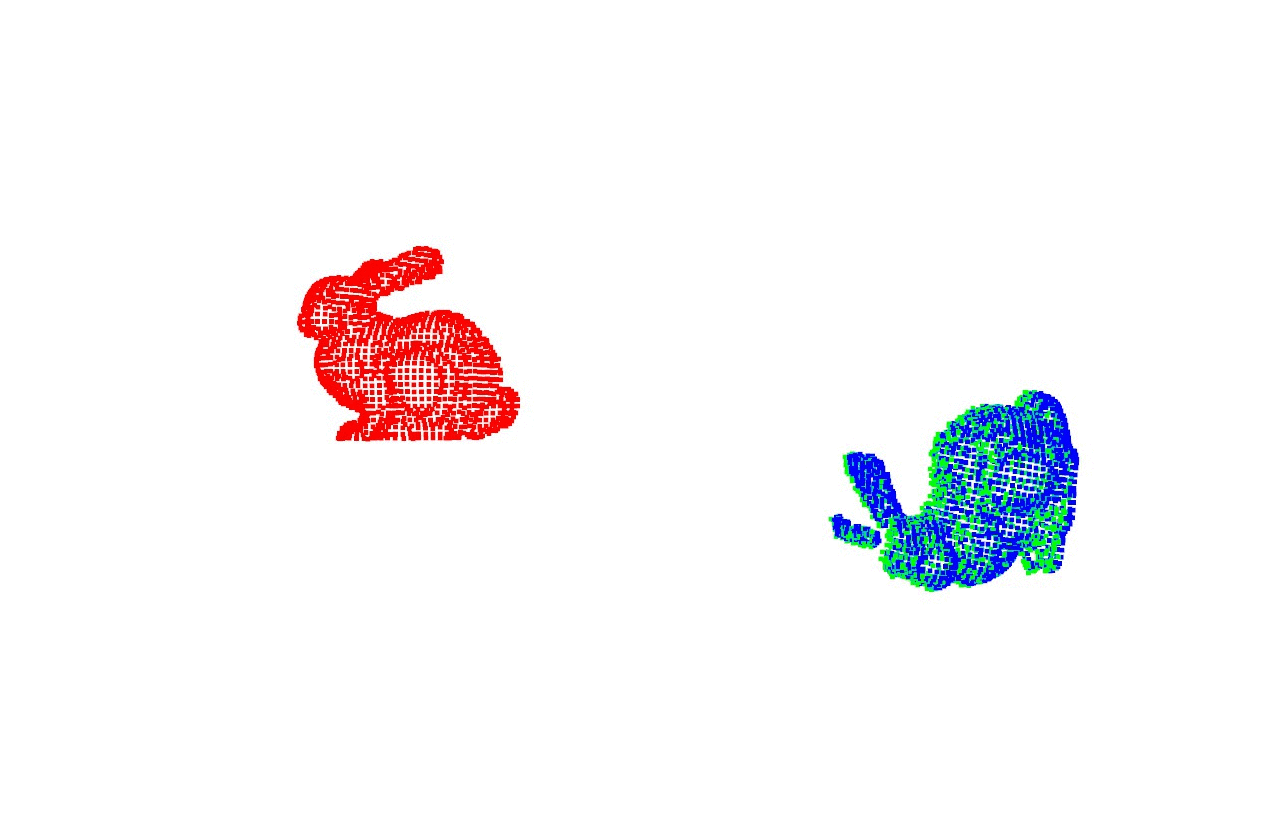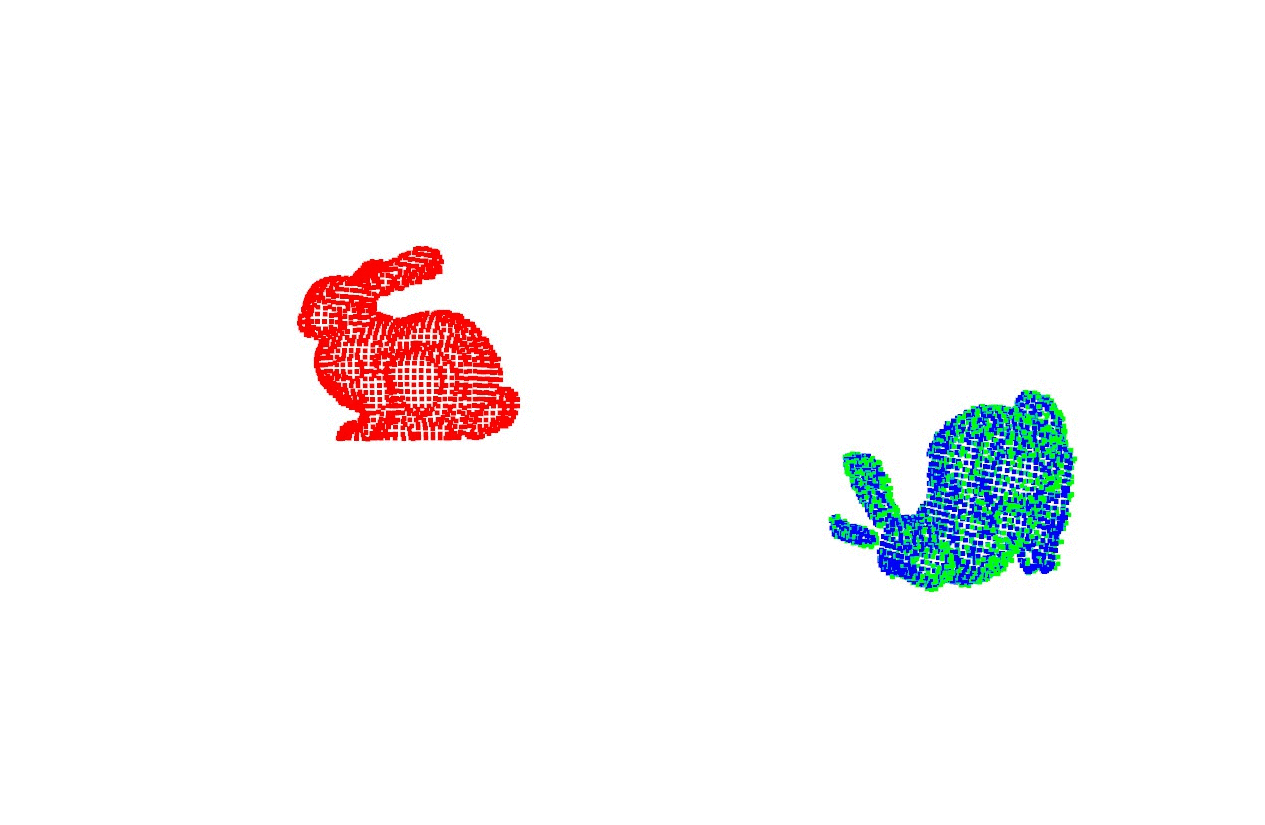 |
Execute an example script for measuring time.
OMP_NUM_THREADS=1 python time_measurement.py

# Results [s]
# ICP(Open3D):  0.0014092829951550812
# CPD:  0.038112225010991096
# SVR:  0.036476270004641265
# GMMTree:  0.10535842599347234
# FilterReg:  0.005098833993542939
@software{probreg,
    author = {{Kenta-Tanaka et al.}},
    title = {probreg},
    url = {https://probreg.readthedocs.io/en/latest/},
    version = {0.1.6},
    date = {2019-9-29},
}