


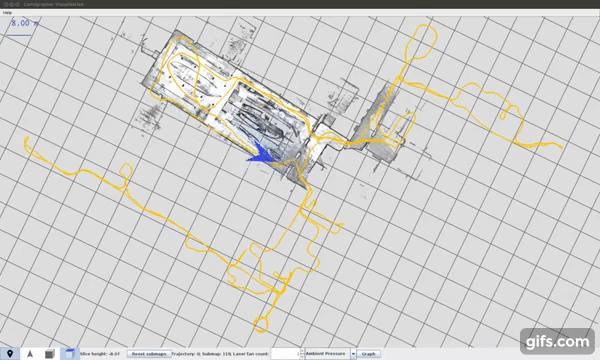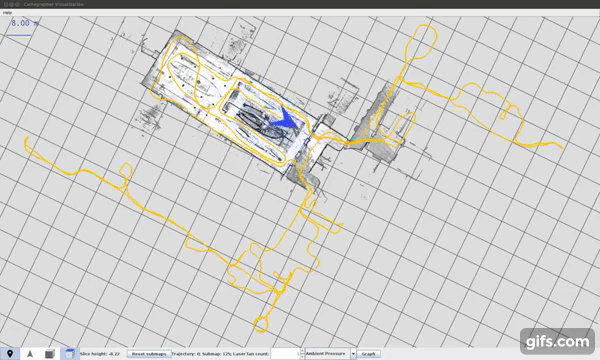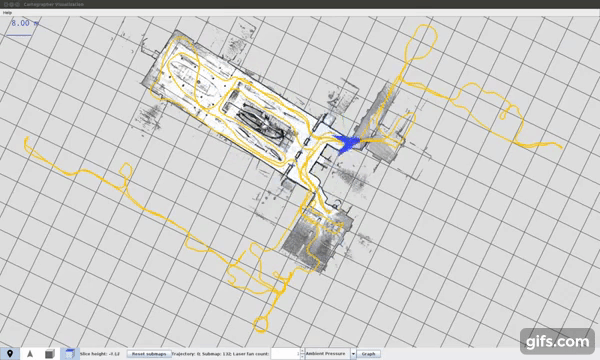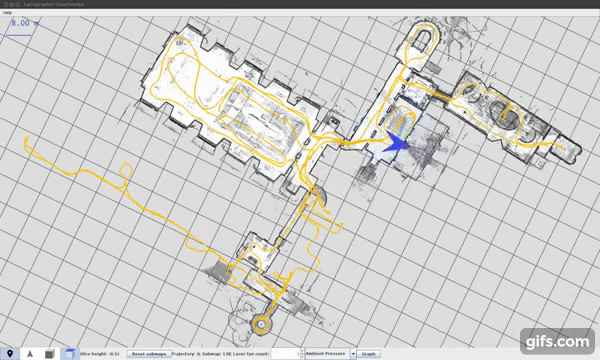
Cartographer is a system that provides real-time simultaneous localization and mapping (SLAM) in 2D and 3D across multiple platforms and sensor configurations.
Cartographer is no longer actively maintained. On rare occasions critical pull requests may be merged, but no new development is currently taking place, including issue response. If you are installing Cartographer in ROS 1 / ROS 2 using a binary package that package is a fork of this repository. The ROS fork of Cartographer is only maintained in a limited capacity. No new development takes place on this fork, but pull requests may be merged at the maintainers' discretion.
The ROS fork of Cartographer, and the ROS wrapper library, can be found at these locations:
Additional discussion can be found in `this ROS Discourse thread<https://discourse.ros.org/t/rolling-and-soon-humble-release-of-both-cartographer-and-cartographer-ros-v2-and-call-for-testing/25137>`_.
- Learn to use Cartographer at our Read the Docs site.
- You can ask a question by creating an issue.
You can find information about contributing to Cartographer at our Contribution page.
In the past there had been regular open-for-all meetings to discuss progress and plans for Cartographer. Slides of these Cartographer Open House meetings are listed below.
- March 14, 2019: Slides
- February 21, 2019: Slides
- January 17, 2019: Slides
- November 22, 2018: Slides
- October 25, 2018: Slides
- September 13, 2018: Slides
- August 16, 2018: Slides
- August 2, 2018: Slides
- July 5, 2018: Slides
- June 21, 2018: Slides
- June 7, 2018: Slides
- May 24, 2018: Slides
- May 3, 2018: Slides
- March 29, 2018: Slides
- February 22, 2018: Slides
- February 8, 2018: Slides
- January 18, 2018: Slides
- January 11, 2018: Slides
- December 7, 2017: Slides
- November 23, 2017: Slides
- November 9, 2017: Slides
- October 26, 2017: Slides
- October 12, 2017: Slides
- September 14, 2017: Slides
- August 17, 2017: Slides
- July 20, 2017: Slides
- July 6, 2017: Slides
- June 22, 2017: Slides
- June 8, 2017: Slides